Muhammad Kamal
Earthling for
MUHAMMAD KAMAL ·
MUHAMMAD KAMAL ·
Robotics and Computer Vision Engineer
Muhammad Kamal Portrait
Multidisciplinary Physics Researcher
Applied Machine Learning and Data Scientist
Current position

Senior Research Assistant at ITB

LocationBandung, West Java, Indonesia

Please, Call Me Kamal.

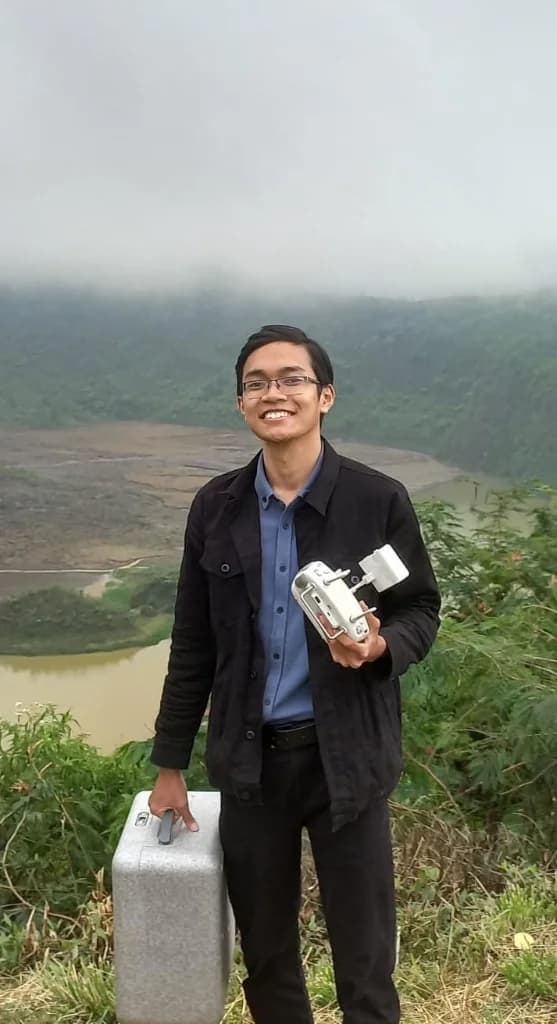
Kamal holding a drone controller
GND VCC SCL SDA
10KΩ POTVOLT_CTRL
12V5V0V
5.0VNOMINAL
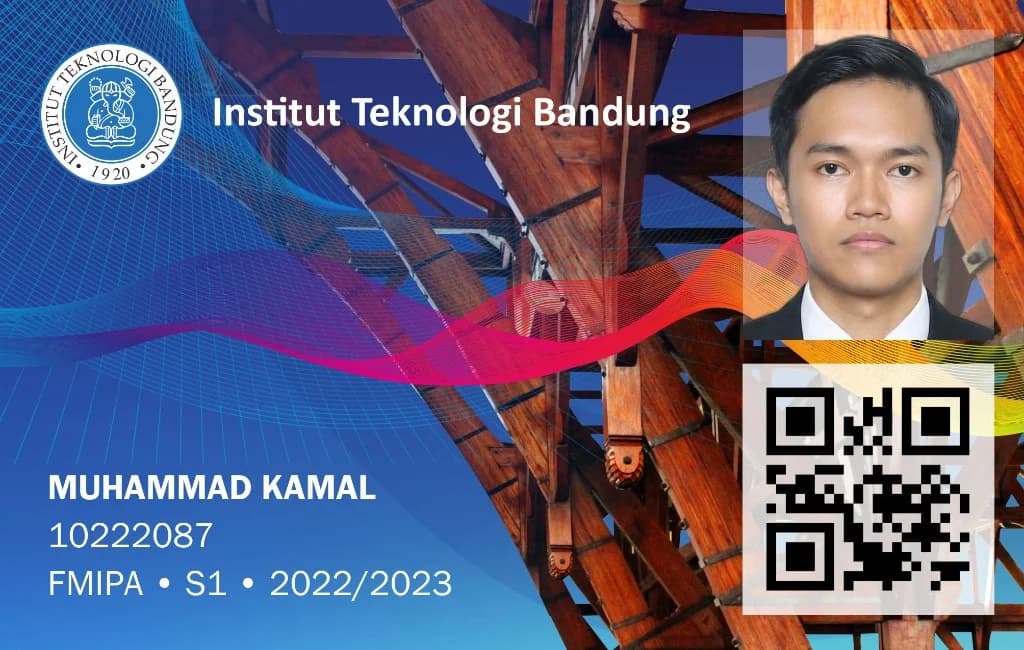
Student ID Card

Full-time physics researcher.

Part-time robotics (computer vision specialist) and ML engineer.

Overtime Dr. Frankenstein, "Frankensteining" discarded electronics into terrifying new life on the weekends.

Shoot me an email, explore my code on GitHub, or catch me on LinkedIn and Instagram!

Explore Selected Projects
Working Philosophy

Kamal's First-Principles Manifesto

Core operating principles for approaching theoretical physics, experimental hardware, and production engineering systems.

Physics Research

Architecting advanced instrumentation and high-speed DAQ for complex physics challenges. Proven through defense-sector R&D at PT Pindad.

PythonPython
L
LabVIEW
A
Altium Designer
KiCadKiCad
SolidWorksSolidWorks
C/C++C/C++
STM32STM32
ESP32ESP32
F
FPGA/VHDL
PythonPython
L
LabVIEW
A
Altium Designer
KiCadKiCad
SolidWorksSolidWorks
C/C++C/C++
STM32STM32
ESP32ESP32
F
FPGA/VHDL
PythonPython
L
LabVIEW
A
Altium Designer
KiCadKiCad
SolidWorksSolidWorks
C/C++C/C++
STM32STM32
ESP32ESP32
F
FPGA/VHDL
Embedded Systems
Opto-Mechanical Design
Digital Signal Processing (DSP)
Data Acquisition (DAQ)
High-Precision Metrology
Sensor Calibration & Fusion
Hardware-in-the-Loop (HIL)
Embedded Systems
Opto-Mechanical Design
Digital Signal Processing (DSP)
Data Acquisition (DAQ)
High-Precision Metrology
Sensor Calibration & Fusion
Hardware-in-the-Loop (HIL)
Embedded Systems
Opto-Mechanical Design
Digital Signal Processing (DSP)
Data Acquisition (DAQ)
High-Precision Metrology
Sensor Calibration & Fusion
Hardware-in-the-Loop (HIL)

Robotics & Vision

Engineering autonomous SLAM and vision architectures. Validated by deploying navigation stacks for Japanese industrial robotics and volcanic search-and-rescue.

C++C++
PythonPython
ROS/ROS2ROS/ROS2
OpenCVOpenCV
P
PCL
TensorRTTensorRT
OpenVINOOpenVINO
ONNXONNX
C++C++
PythonPython
ROS/ROS2ROS/ROS2
OpenCVOpenCV
P
PCL
TensorRTTensorRT
OpenVINOOpenVINO
ONNXONNX
C++C++
PythonPython
ROS/ROS2ROS/ROS2
OpenCVOpenCV
P
PCL
TensorRTTensorRT
OpenVINOOpenVINO
ONNXONNX
Visual SLAM (ORB-SLAM3)
Autonomous Navigation (Nav2)
Sensor Fusion (EKF / IMU)
3D LiDAR & Point Cloud (PCL)
Trajectory & Path Planning
Embedded Edge AI (TensorRT)
Visual SLAM (ORB-SLAM3)
Autonomous Navigation (Nav2)
Sensor Fusion (EKF / IMU)
3D LiDAR & Point Cloud (PCL)
Trajectory & Path Planning
Embedded Edge AI (TensorRT)
Visual SLAM (ORB-SLAM3)
Autonomous Navigation (Nav2)
Sensor Fusion (EKF / IMU)
3D LiDAR & Point Cloud (PCL)
Trajectory & Path Planning
Embedded Edge AI (TensorRT)

Machine Learning & AI

Deploying foundation vision models and MLOps pipelines. Delivered production-grade AI solutions for energy leaders Pertamina (OGI MWIR plume vision), BP, KUFPEC (LRLC logging workflows), and Halliburton.

PyTorchPyTorch
TensorFlowTensorFlow
Node-REDNode-RED
P
PLC/MES
GitGit
GrafanaGrafana
InfluxDBInfluxDB
PostgreSQLPostgreSQL
PyTorchPyTorch
TensorFlowTensorFlow
Node-REDNode-RED
P
PLC/MES
GitGit
GrafanaGrafana
InfluxDBInfluxDB
PostgreSQLPostgreSQL
PyTorchPyTorch
TensorFlowTensorFlow
Node-REDNode-RED
P
PLC/MES
GitGit
GrafanaGrafana
InfluxDBInfluxDB
PostgreSQLPostgreSQL
Deep Learning (PyTorch)
Computer Vision (YOLO / SAM)
Physics-Informed ML (PINNs / KAN)
Model Quantization (FP16/INT8)
Edge Inference Optimization
MLOps & CI/CD
Industrial IoT Telemetry
Deep Learning (PyTorch)
Computer Vision (YOLO / SAM)
Physics-Informed ML (PINNs / KAN)
Model Quantization (FP16/INT8)
Edge Inference Optimization
MLOps & CI/CD
Industrial IoT Telemetry
Deep Learning (PyTorch)
Computer Vision (YOLO / SAM)
Physics-Informed ML (PINNs / KAN)
Model Quantization (FP16/INT8)
Edge Inference Optimization
MLOps & CI/CD
Industrial IoT Telemetry

Optics & Laser Engineering

Designing precision opto-mechanical modules and integrated laser systems. Demonstrated via femtosecond X-ray diffraction (XRD) research at POSTECH, South Korea.

Z
Zemax OpticStudio
C
COMSOL
SolidWorksSolidWorks
P
PANalytical
J
Jade
M
MATLAB
PythonPython
Z
Zemax OpticStudio
C
COMSOL
SolidWorksSolidWorks
P
PANalytical
J
Jade
M
MATLAB
PythonPython
Z
Zemax OpticStudio
C
COMSOL
SolidWorksSolidWorks
P
PANalytical
J
Jade
M
MATLAB
PythonPython
Ultrafast Laser Optics
Femtosecond Spectroscopy (Pump-Probe)
THz-TDS Metrology
Coherent Diffraction & Ptychography
Opto-Mechanical Engineering
Vibration Isolation & Alignment
X-Ray Scattering (Synchrotron)
Ultrafast Laser Optics
Femtosecond Spectroscopy (Pump-Probe)
THz-TDS Metrology
Coherent Diffraction & Ptychography
Opto-Mechanical Engineering
Vibration Isolation & Alignment
X-Ray Scattering (Synchrotron)
Ultrafast Laser Optics
Femtosecond Spectroscopy (Pump-Probe)
THz-TDS Metrology
Coherent Diffraction & Ptychography
Opto-Mechanical Engineering
Vibration Isolation & Alignment
X-Ray Scattering (Synchrotron)

Projects & Systems

Showing 9 selected flagship projects
University · Thesis ResearchB.Sc. Thesis & Capstone ResearchVolcanic Robotics & VINS
Collaborated withBRIN
ITB
PVMBGESDM
2x AIP Papers

PRAWIRA: Perangkat Kendaraan Tanpa Awak untuk Wilayah Rawan

“Engineering of a Visual-Inertial Navigation System Based on a Passive Stereo Camera with a Comparative Analysis of Depth Estimation Methods for Volcano Monitoring Mobile Robot Applications”

As my undergraduate capstone and B.Sc. thesis research under Prof. Mitra Djamal, Dr. Maria Evita, and Dr. Eng. Arief Suryadi S. in collaboration with BRIN and PVMBG ESDM, I engineered a complete Visual-Inertial Navigation System (VINS) for active volcano monitoring and disaster mitigation.

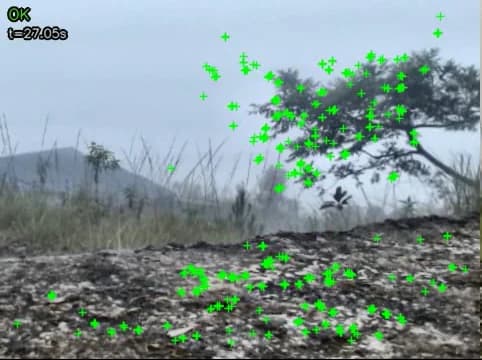
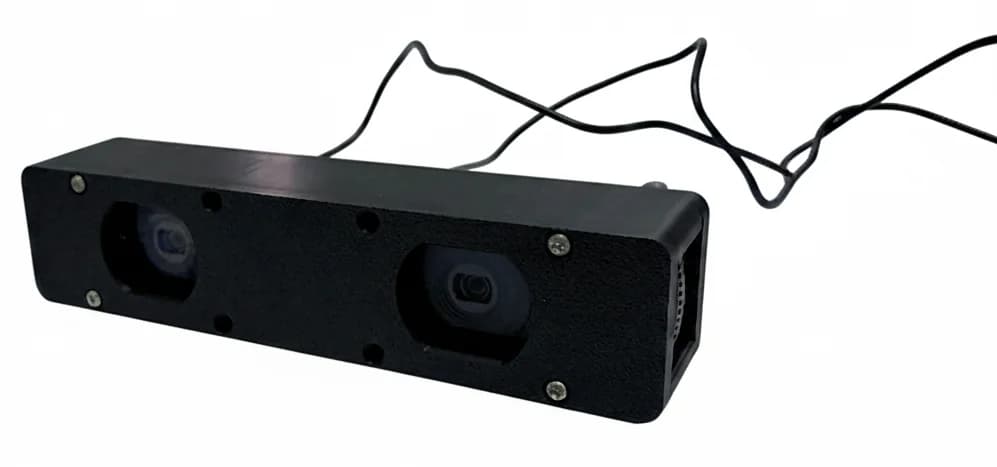
Designed and calibrated a custom stereo camera rig from scratch, benchmarking lightweight deep stereo matching against monocular metric depth estimation to synthesize reliable 3D point clouds in volcanic ash terrains where LIDAR sensors fail. Created an ORB-SLAM3 V-SLAM system tightly coupled with an MPU IMU for robust 6-DoF autonomous navigation across unstructured and GPS-denied volcanic crater environments.

This research resulted in two first-author AIP Conference proceedings:

Mt. Galunggung Terrain
Mt. Galunggung
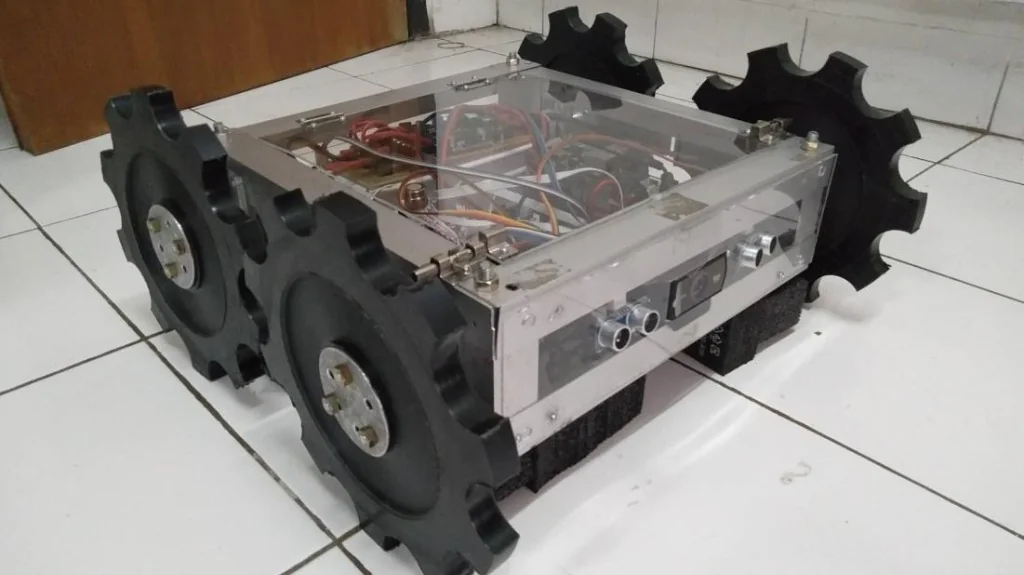
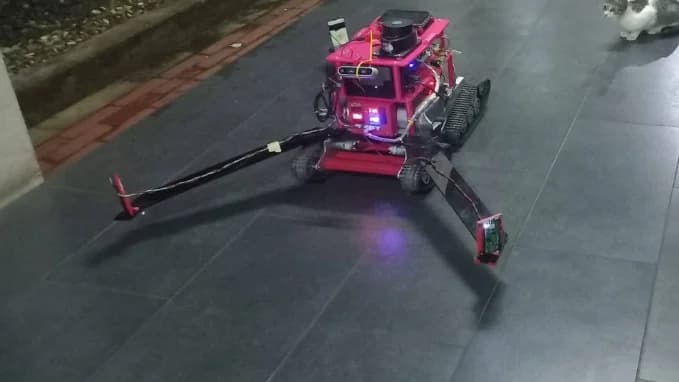
PRAWIRA Robot IRL
Robot IRL
Tracking Features
V-SLAM ORBs
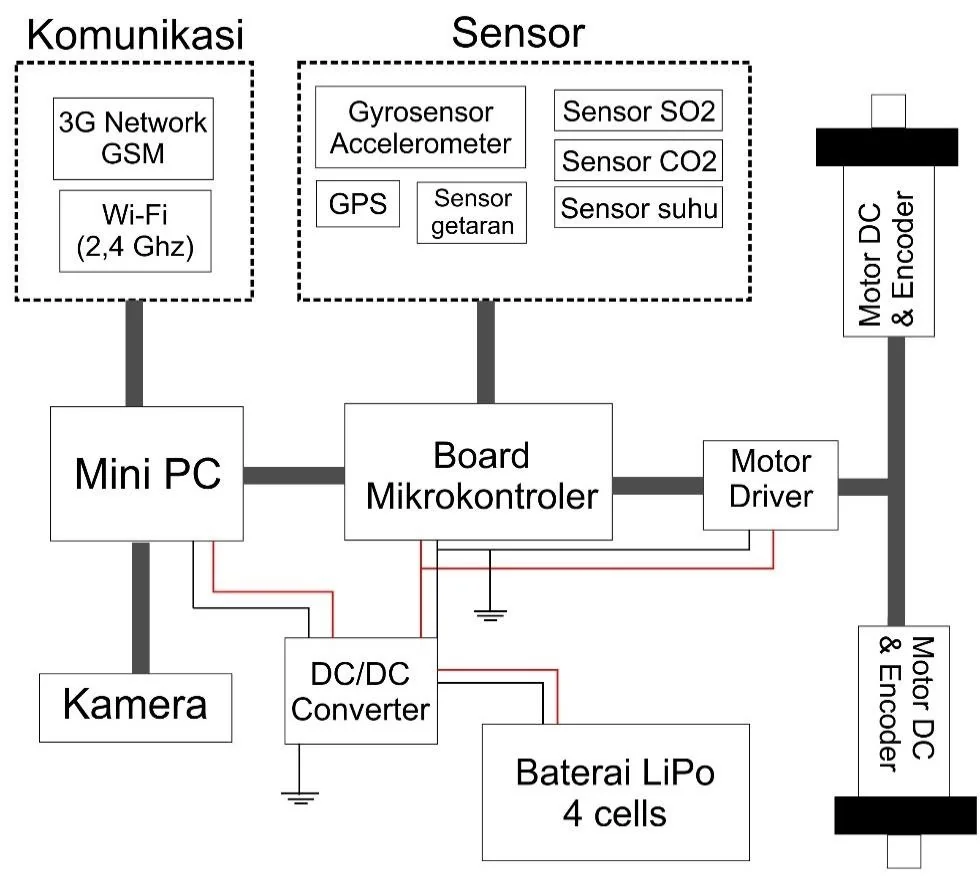
System Schematic
Architecture
Custom Stereo Camera
Stereo Rig
Loading 3D Telemetry...
Technologies & Methodologies:
ROS 2C++17 / C++20PythonVisual SLAM (ORB-SLAM3)Visual-Inertial Odometry (VIO)Stereo Matching (RAFT-Stereo)Metric Depth EstimationSensor Fusion (EKF / 9-DoF IMU)Point Cloud Library (PCL)NVIDIA TensorRTONNX RuntimeEmbedded Edge AI (Jetson)3D ReconstructionAutonomous Mobile Robots (AMR)
Real Work · IndustryRobotics for Industrial Implementation
Collaborated with
Nakayama Iron Works
Japan
ITB De Labo

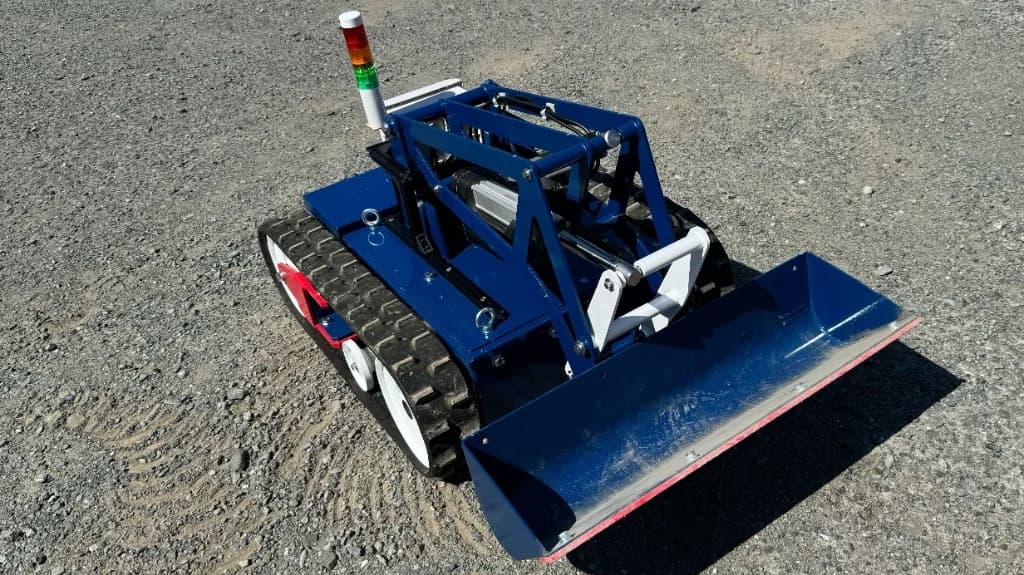
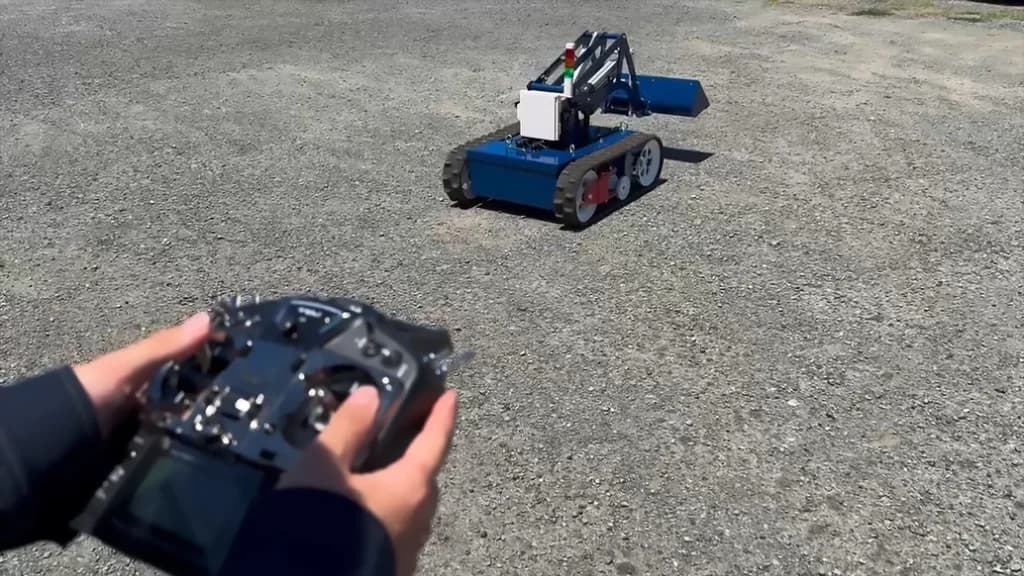
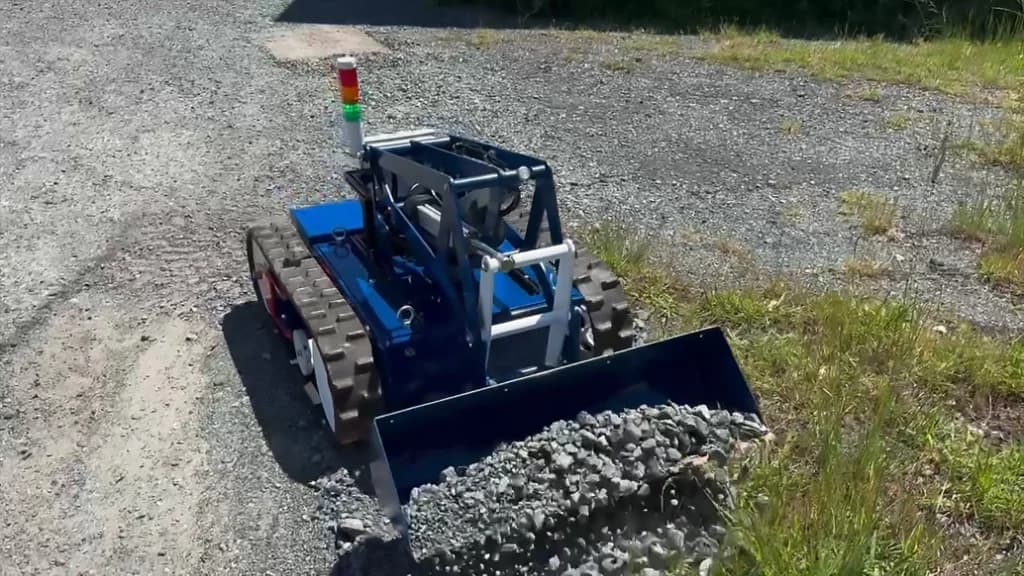
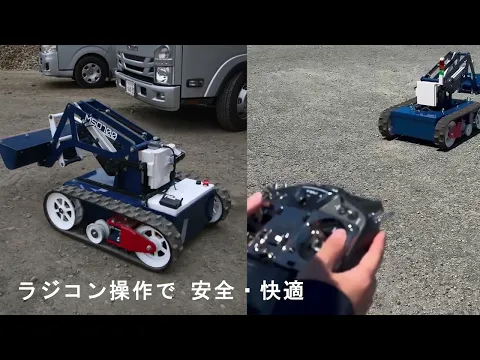
MSD700 Robot

The MSD700 is a heavy-duty industrial robotics platform designed for payload transportation and dynamic environment navigation.

As a core member of the R&D team, I developed the autonomous navigation, trajectory planning stacks, and GPS dashboard systems using sensor fusion (GPS, IMU, depth) and computer vision.

These fail-safe C++/Python architectures successfully enabled real-time obstacle avoidance and reliable Return-to-Home autonomy directly on physical industrial controllers.

Tracked Base
Tracked Base
Teleoperation
Teleoperation
Payload
Payload Testing
Prototype
Early Prototype
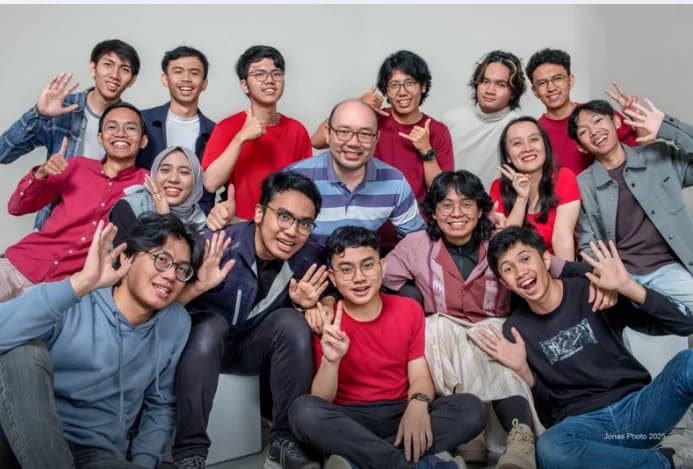
Team
The R&D Team
MSD700 Robot Test
Technologies & Methodologies:
ROS / ROS 2 NavigationC++PythonAutonomous Navigation Stack (Nav2)Global & Local Path Planning (A*, TEB)Dynamic Obstacle AvoidanceSensor Fusion (GPS + 9-DoF IMU + Depth)Costmap2D Spatial MappingKinematics & Pure Pursuit ControlEmbedded LinuxReal-Time Edge ComputingIndustrial Robotics
University · Competition FleetRoboCup Middle Size League
Collaborated withITB
Unit Robotika ITB

Dagozilla MSL

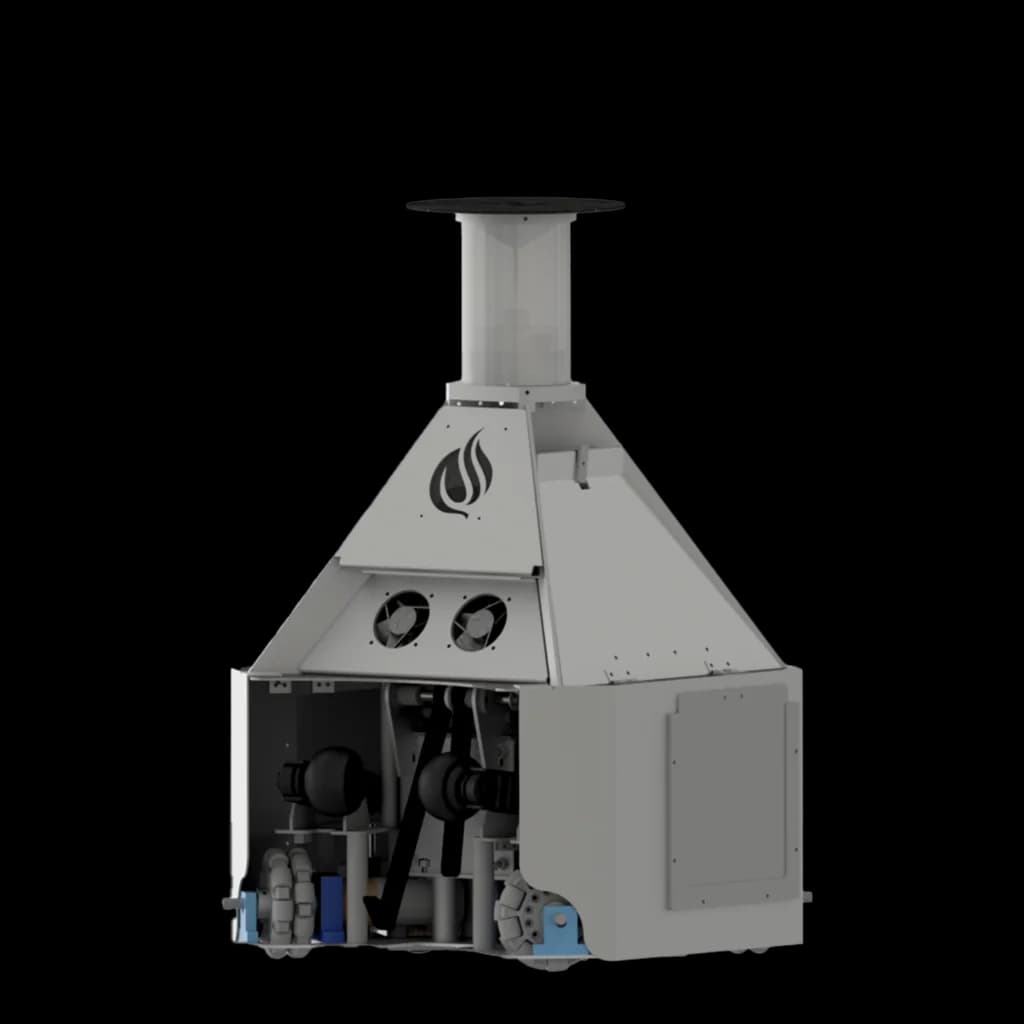
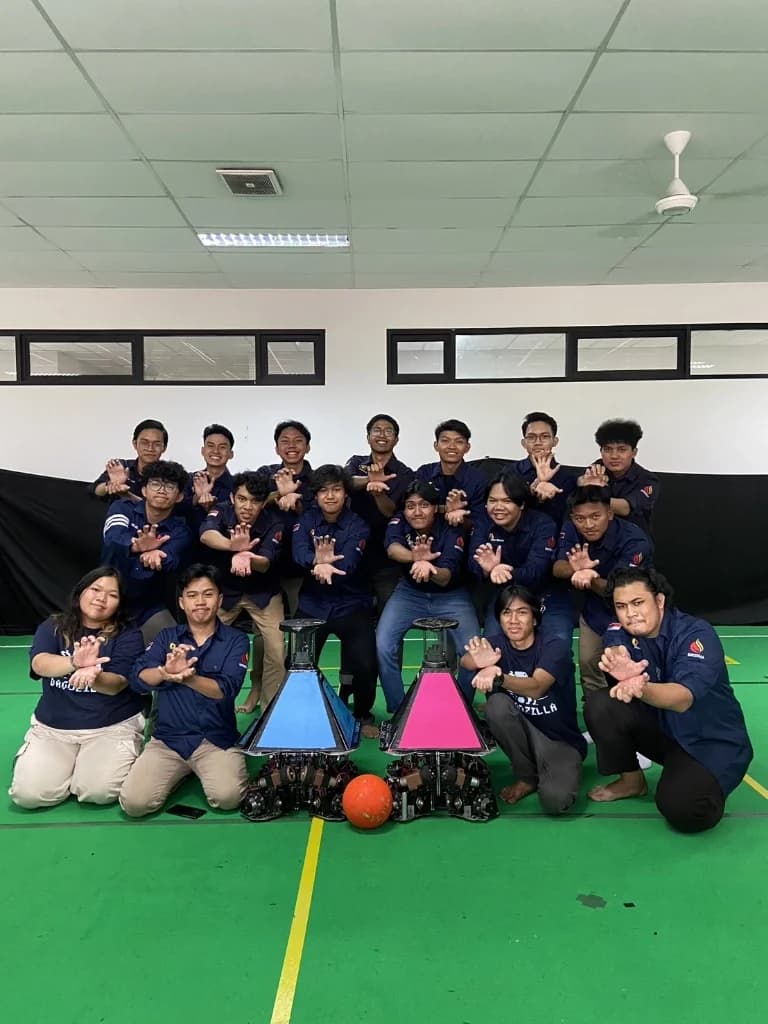
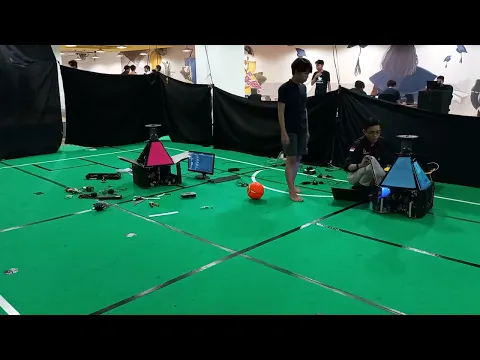
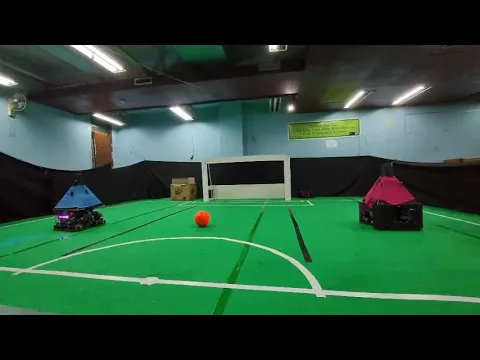
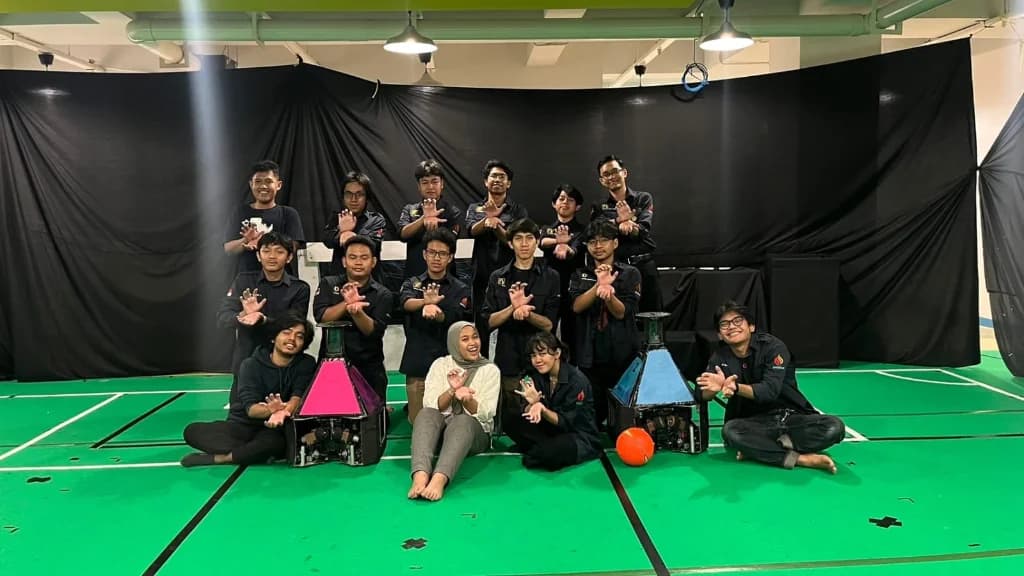
The Dagozilla Team competes in RoboCup's Middle Size League (MSL), building fully autonomous wheeled robots that play competitive 5-on-5 soccer matches without any human intervention in the KRI National Contest.

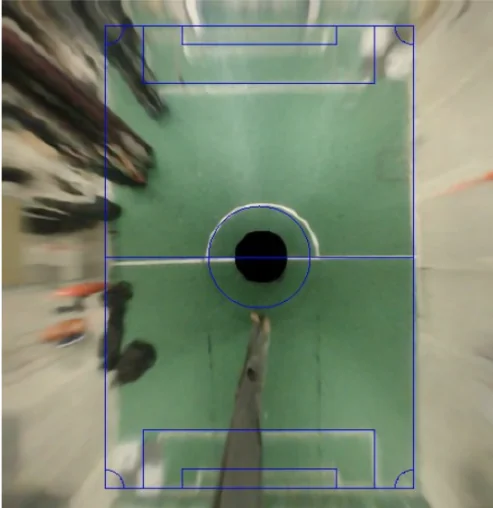
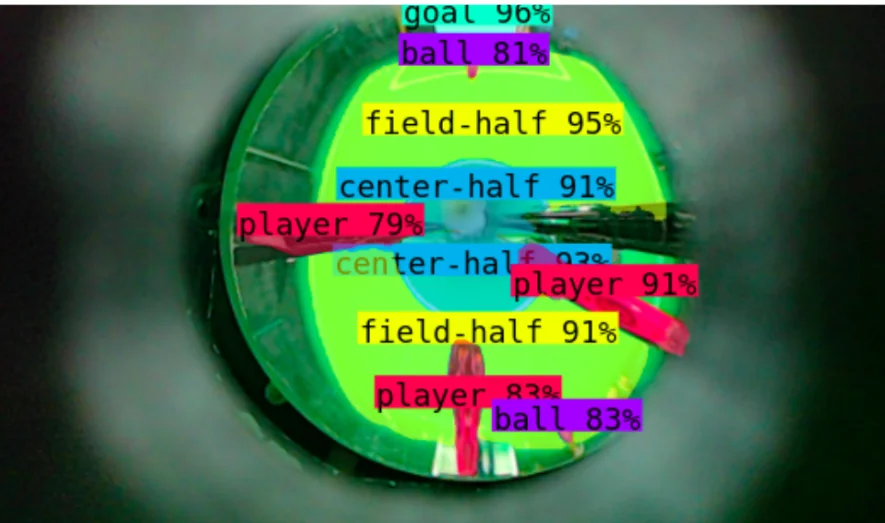
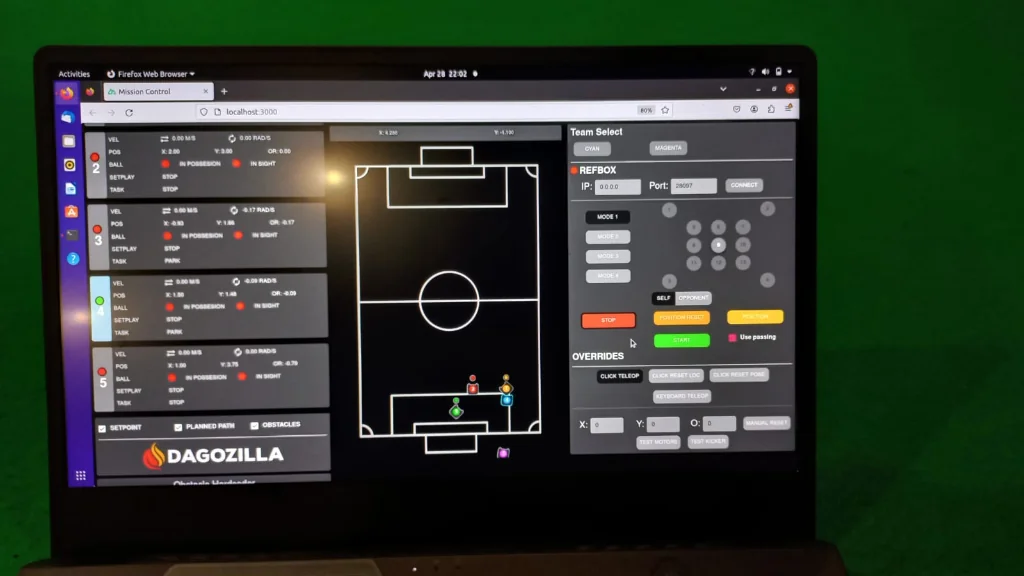
As team lead, I directed 5 engineers to build a 3-robot fleet named Kirchoff, Laplace, and Maxwell, architecting a computer vision pipeline fusing YOLO, SAM2, and RT-DETR with ROS AMCL navigation and C++/Python PID motion control for autonomous dribbling and kicking.

Deploying sensor fusion and automated testing frameworks improved navigation accuracy by 30%, cut code errors by 25%, and accelerated team development cycles by 20%.

Dagozilla Robot
Fleet: Kirchoff, Laplace & Maxwell
Field Map
Field Map
YOLO
YOLO Vision
Tracking
Ball Tracking
Team with Robots
The Team
Full Team
KRI Season
Dashboard
Mission Control
KRI 2024
KRI 2023
Technologies & Methodologies:
ROS / ROS 2C++PythonComputer Vision (OpenCV)Real-Time Object Detection (YOLOv8, RT-DETR)AMCL Monte Carlo LocalizationOmnidirectional KinematicsPID Motion ControlMulti-Agent Fleet CoordinationZero-Latency IPCDeep Learning (PyTorch)Embedded Systems (STM32)
Real Work · IndustryMachine Learning and AI on Industry
Collaborated withPT Pertamina Geothermal
PT LAPI ITB

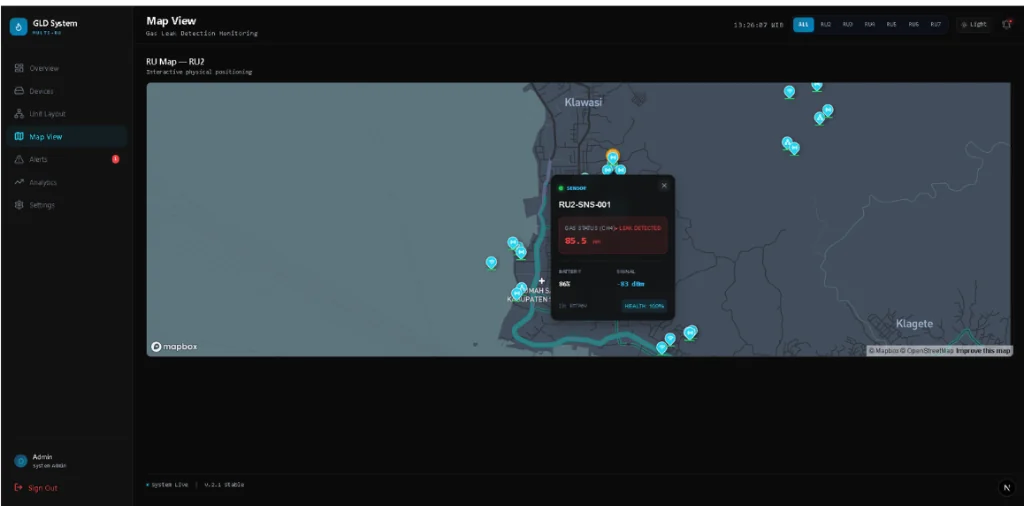
OGI Gas Leak

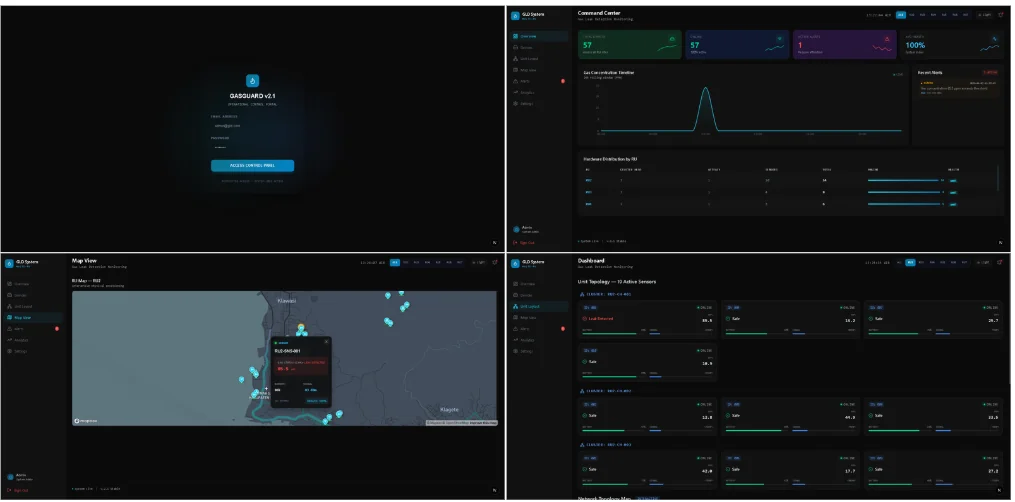
This project is an edge-deployed computer vision and anomaly detection system engineered for high-risk industrial facilities to autonomously identify hazardous hydrocarbon gas leaks and optical plume dispersals in real time.

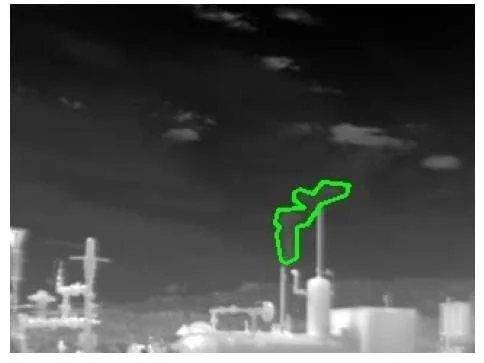
Focusing on machine learning to detect gas anomalies and autonomous gas leaks directly from camera feeds, I engineered a TensorRT-optimized vision pipeline deploying YOLOv8, SAM2, and RT-DETR alongside specialized thermal architectures (GasSeg, LangGas, CGNet) on Jetson Orin Nano edge-servers, fusing legacy point telemetry with PTZ-mounted MWIR optical gas imaging cameras.

This edge architecture sustained 24/7 plume segmentation at 30 FPS across 3+ industrial monitoring sites without thermal throttling, delivering a spatial tracking dashboard that slashed false-positive alerts by 45%, reduced leak identification latency to under 120 milliseconds, and benchmarked hardware configurations over 20+ runs to eliminate integration errors.

LIVE INFERENCE · 30 FPS
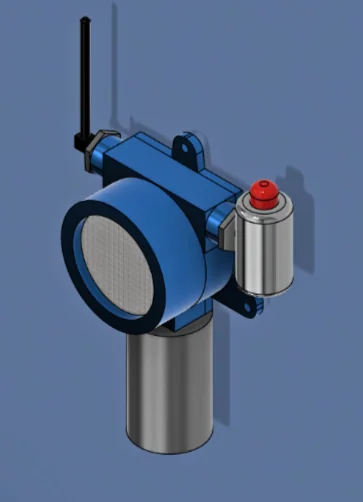
PTZ MWIR Detector
PTZ MWIR Detector
Plume Segmentation
MWIR Plume Seg
Spatial Tracking
Spatial Tracking (RU2)
Command Center
Command Center
Technologies & Methodologies:
Optical Gas Imaging (OGI)Long-Wave & Mid-Wave IR (LWIR/MWIR)Computer Vision (OpenCV)Deep Learning (YOLOv8, SAM 2)Semantic Segmentation (GasSeg, CGNet)NVIDIA Jetson Orin NanoTensorRT Optimization (FP16/INT8)CUDA C++ & PythonReal-Time Edge Inference (30 FPS)Thermal Anomaly DetectionIoT Telemetry (MQTT)
Real Work · Industry & ResearchEnergy Exploration, Subsurface AI & Reservoir Intelligence
Collaborated withPT LAPI ITB
Pertamina
BP
UK
KUFPEC
Kuwait
Halliburton
USA
ITB Reservoir Engineering
Patent-Pending

Subsurface Intelligence: Offshore GIIP Volumetrics, ML Imputation & Physics-Informed ChebyKAN

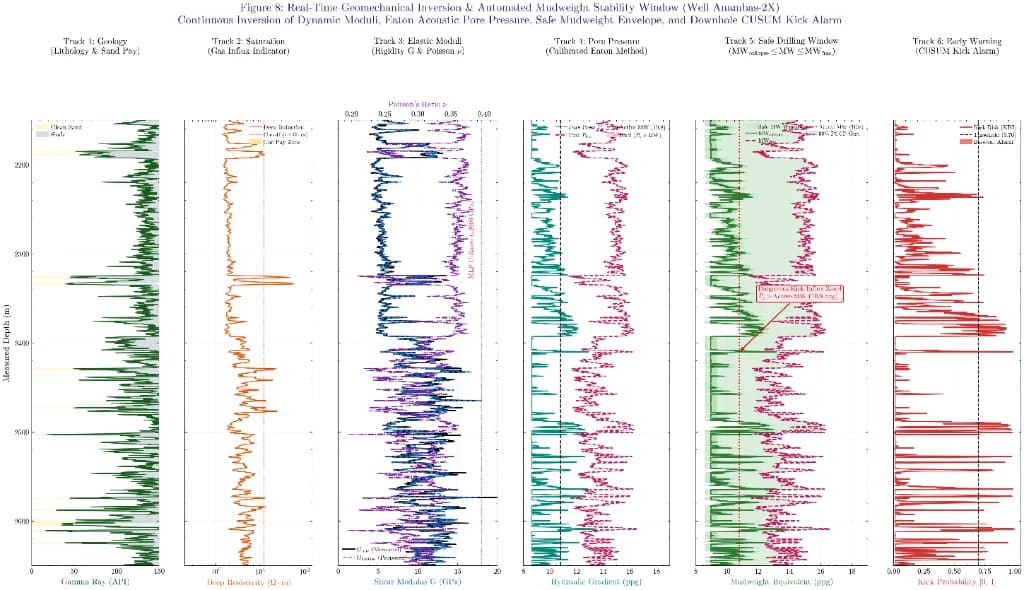
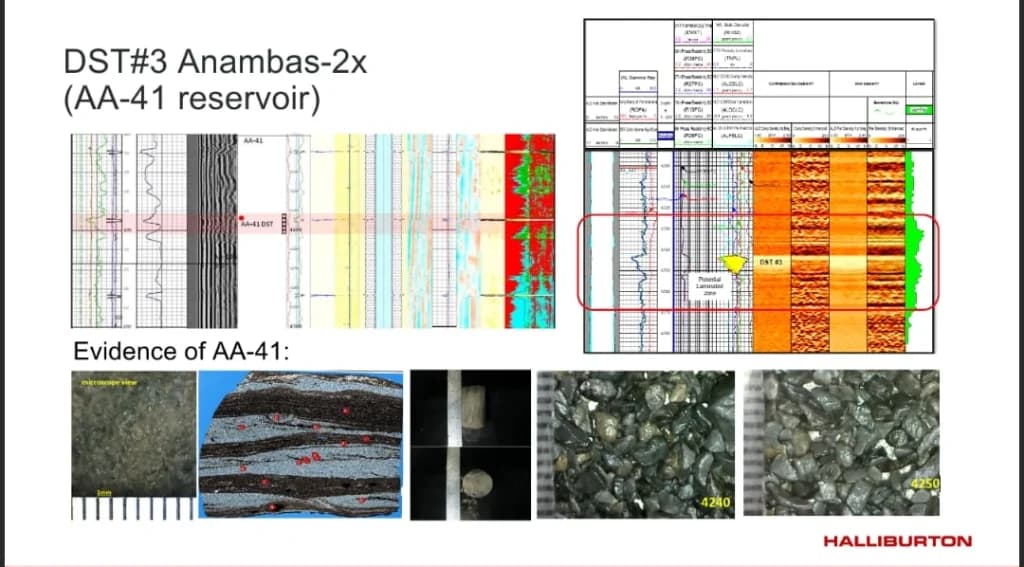
Conducted offshore formation evaluation and reservoir characterization for Anambas exploration wells alongside PT LAPI ITB, Pertamina, BP, KUFPEC, and Halliburton, screening proprietary logging workflows across 10+ client deliverables to de-risk multi-million-dollar energy investments. Automated Python and Julia tensor pipelines to impute missing well logs, analyze core scanner data (LIBS, XRF, hyperspectral, RGB core photo), and compute water saturation in complex LRLC reservoirs via hardcoded Modified Simandoux and Thomas-Stieber algorithms, accelerating multidisciplinary interpretation timelines by 45%.

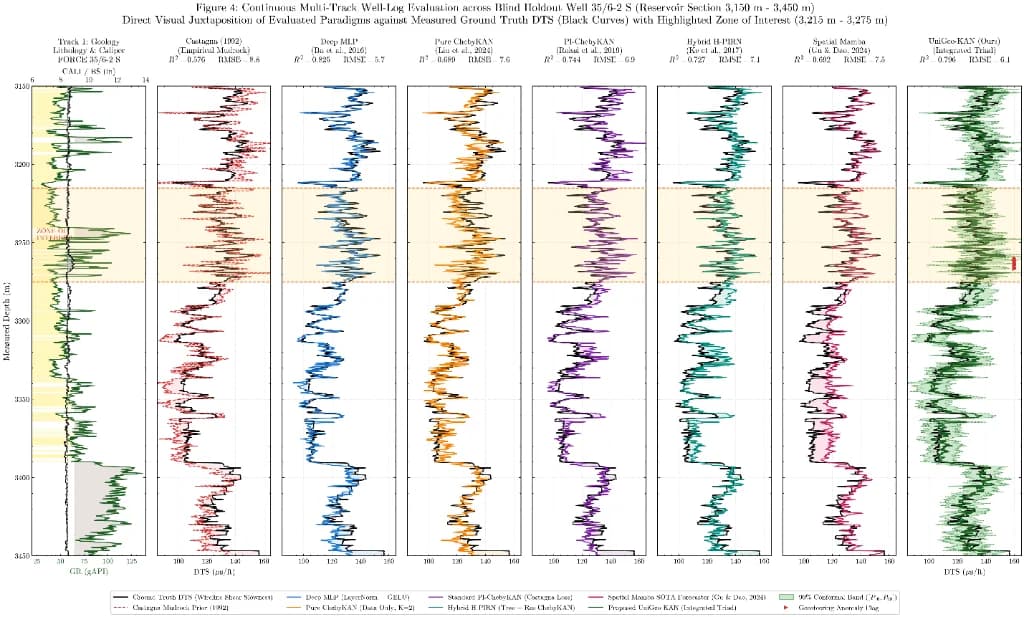
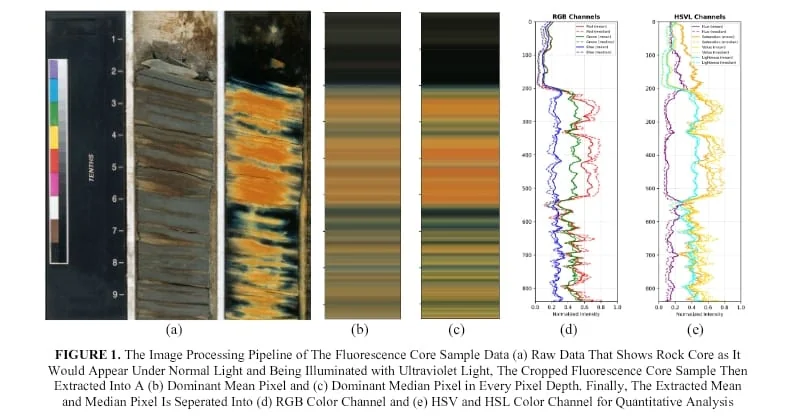
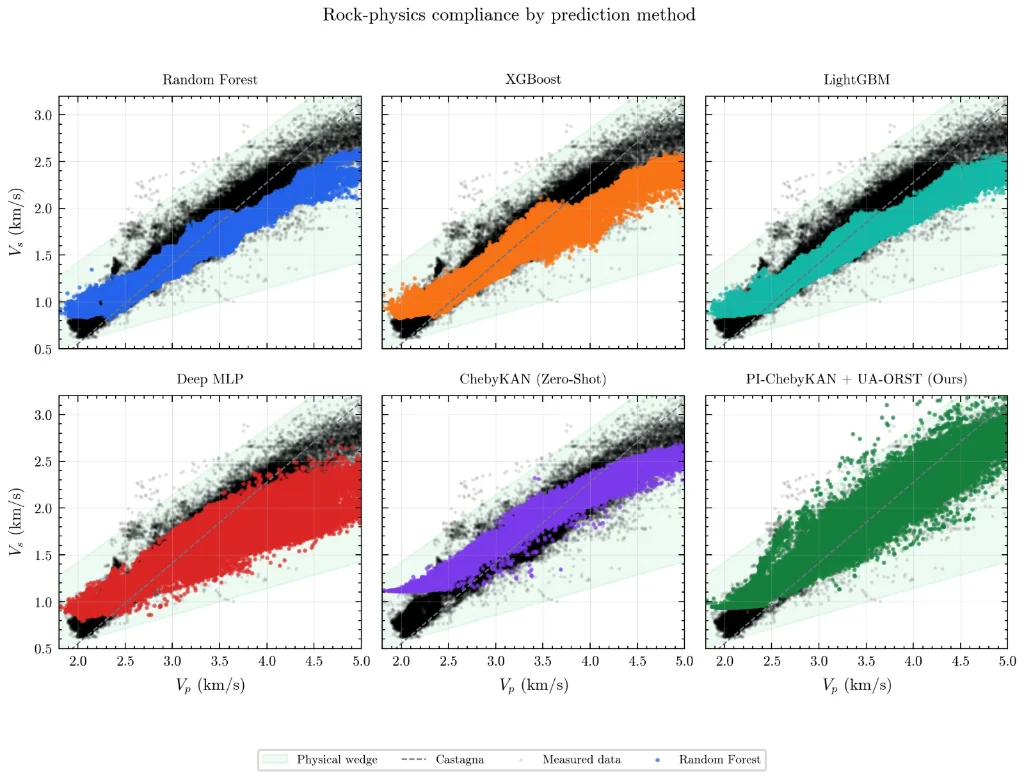
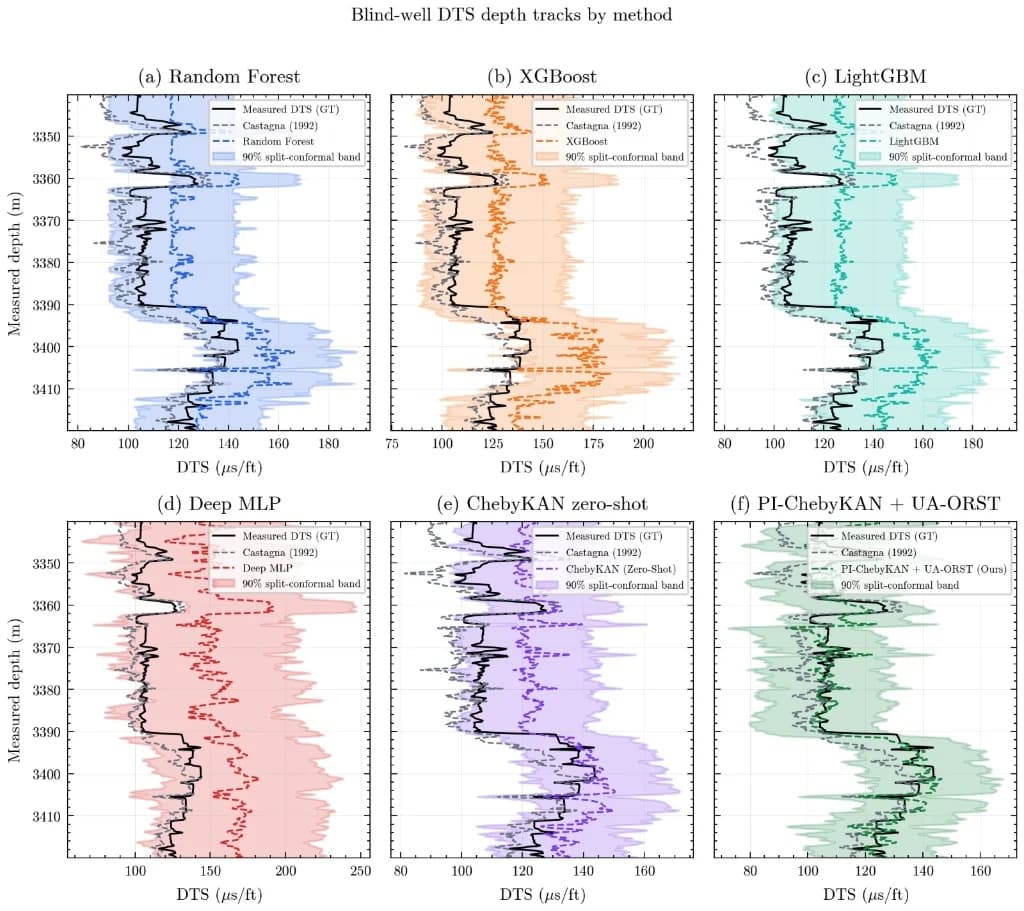
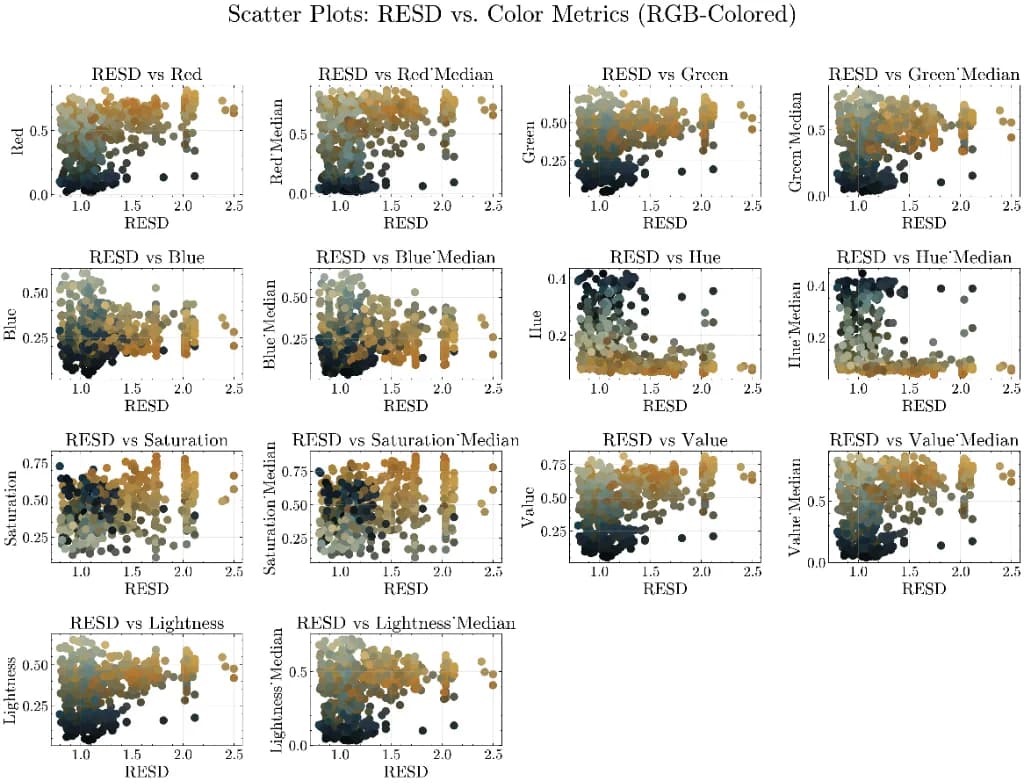
In joint research with ITB Reservoir Engineering, co-invented a patent-pending Python/C++ framework using OpenCV to extract geological textures from RGB core imagery, boosting resistivity prediction accuracy to 90% (+5 point gain) and cutting turnaround from 3 days to 1 day. Coupled Physics-Informed ChebyKAN neural networks with UA-ORST spatial tracking to predict drilling parameters and shear-sonic logs (DTS) with strict rock-physics compliance, reaching 0.895 R² on DTS benchmarks, limiting underbalance violations to 3.7%, and reducing raw acquisition overhead by 37% across 4 multi-well domains.
Geomechanical Inversion & Mudweight Stability
WELL ANAMBAS-2X · REAL-TIME GEOMECHANICS
Continuous Multi-Track Well-Log Evaluation
BLIND HOLDOUT 35/6-2 S · UNIGEO-KAN
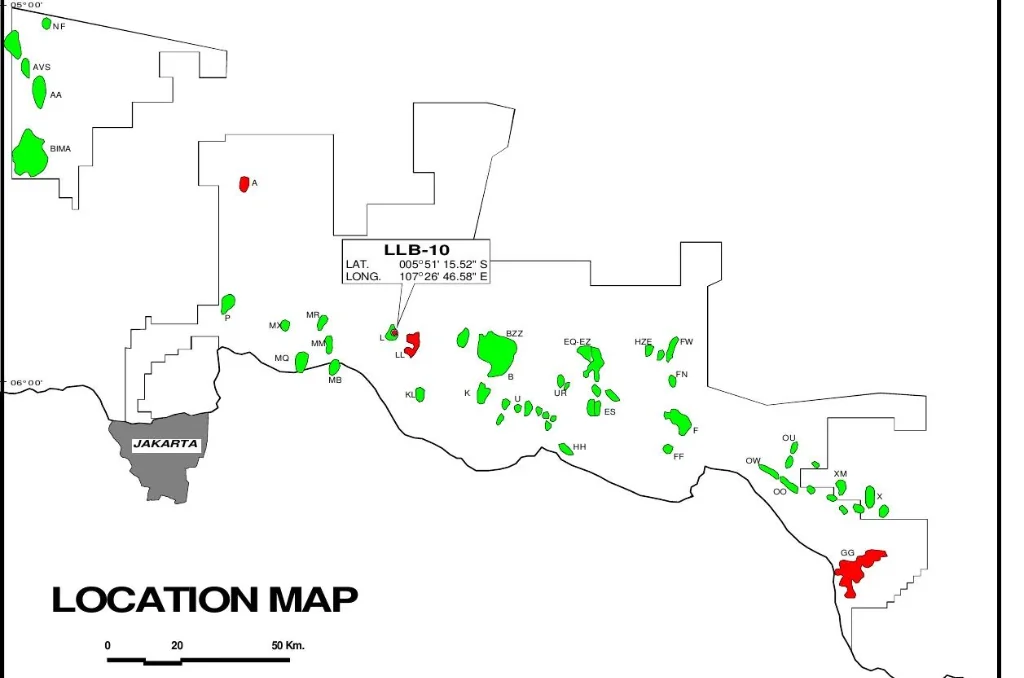
Offshore Exploration Map
Offshore Basin
Anambas Well Log
DST#3 Reservoir Log
Core Fluorescence CV
Rock-Physics Compliance
Rock-Physics (Vs vs Vp)
DTS Depth Tracks
DTS Depth Tracks
PCA Color Features
PCA Color ⊓ RESD
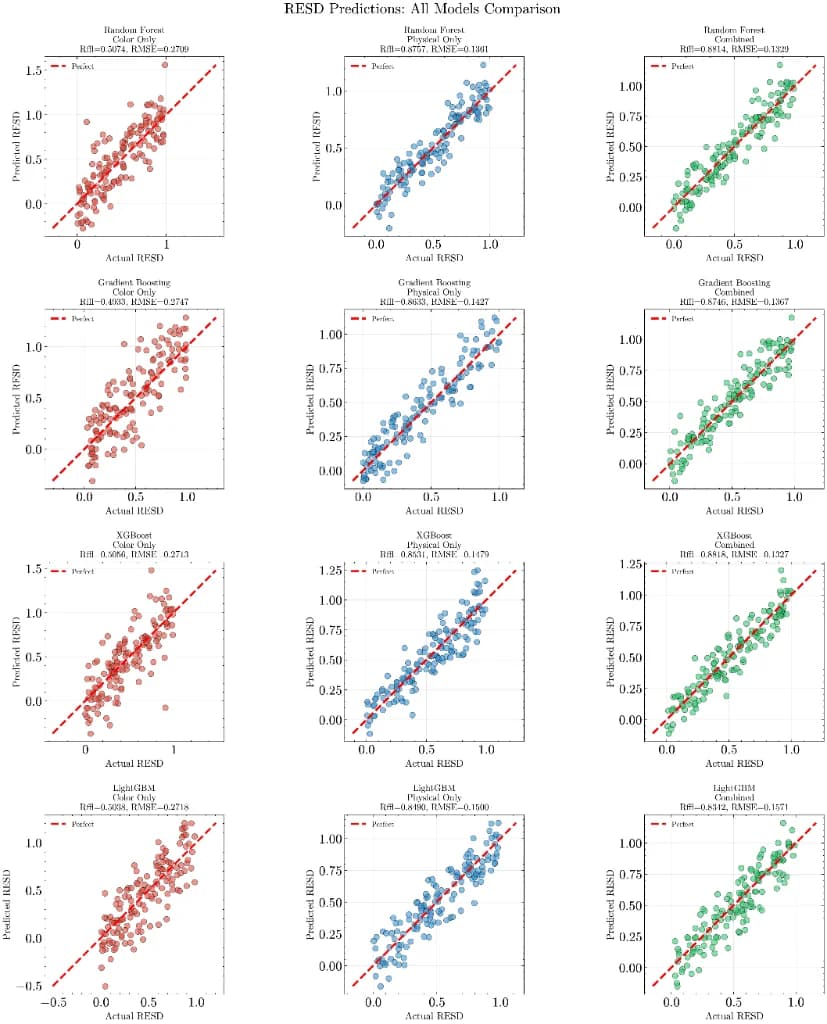
RESD Model Comparison
Model Comparison
RESD Scatter Metrics
RESD Metrics
Technologies & Methodologies:
Physics-Informed Neural Networks (PINNs)Kolmogorov-Arnold Networks (ChebyKAN)Scientific Machine Learning (SciML)PyTorchPythonJuliaGeomechanical InversionPetrophysical Modeling (Simandoux)Missing Data ImputationHyperspectral & Multispectral ImagingSubsurface Reservoir CharacterizationProbabilistic Modeling (Monte Carlo)SQL
University · Research FellowshipUltrafast Quantum Physics & Coherent Imaging
Collaborated with
POSTECH
South Korea

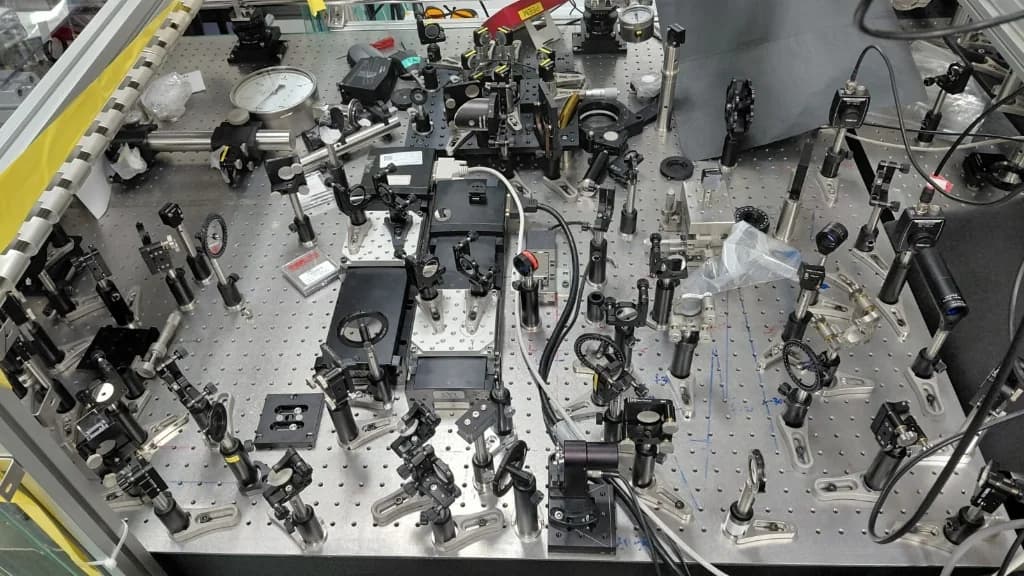
Femtosecond Carrier Dynamics & GPU-Accelerated Ptychography

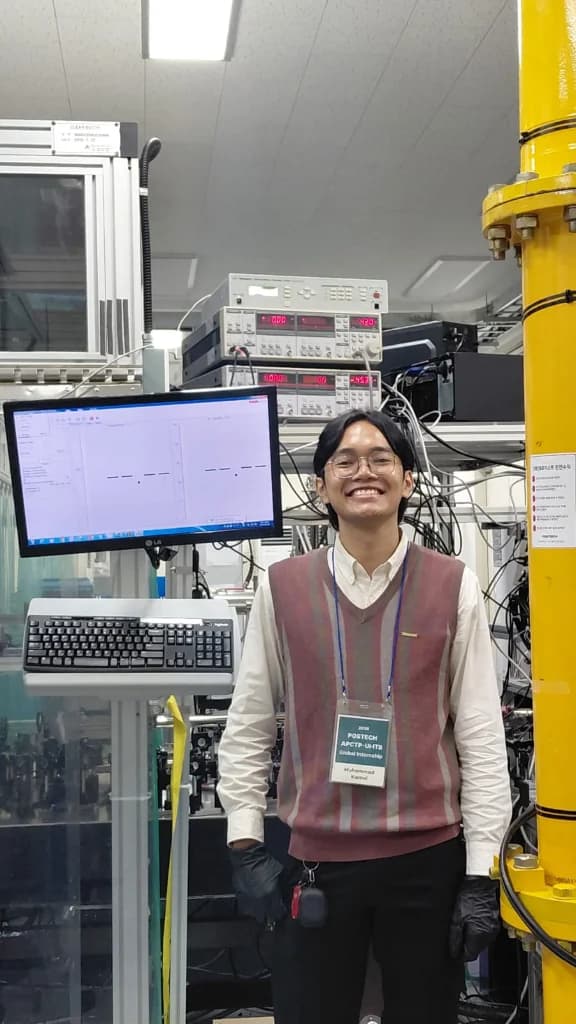
Investigated sub-picosecond carrier dynamics and spin-phonon coupling in Si(001), bulk tungsten, and emergent altermagnets (MnF₂) under Prof. Changyong Song and Jungchan Choi at POSTECH.

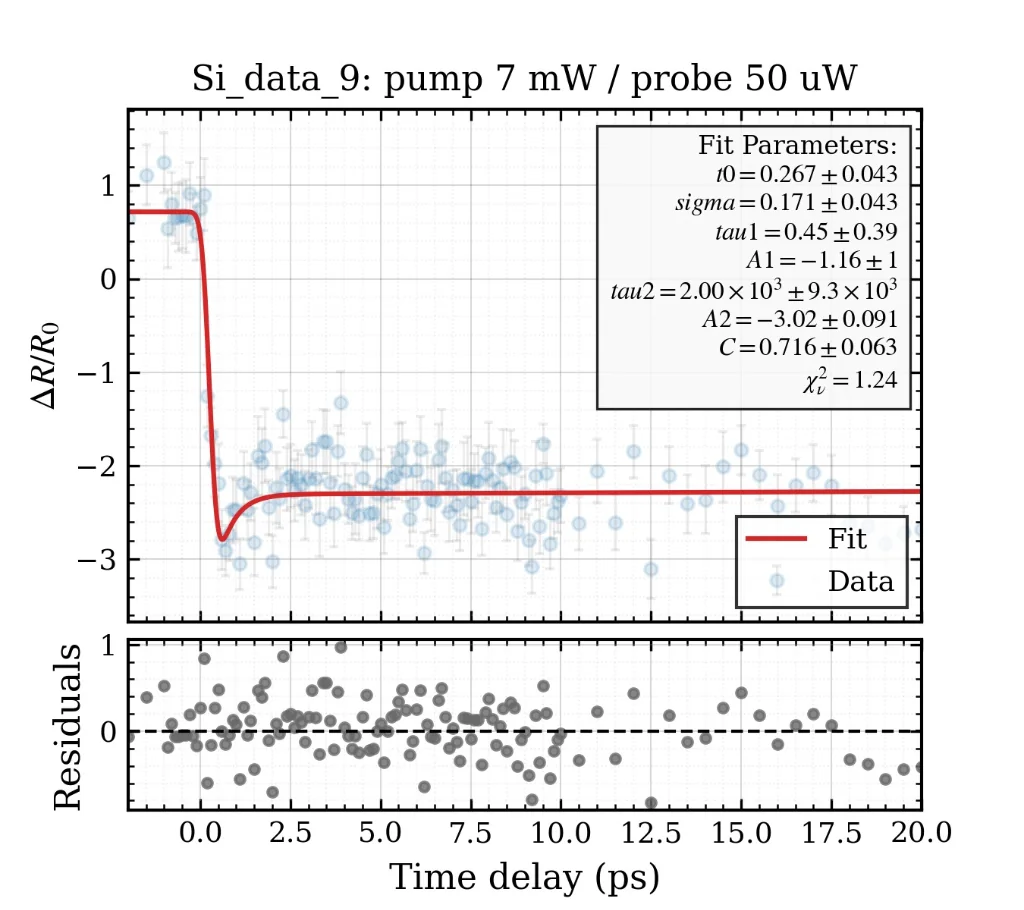
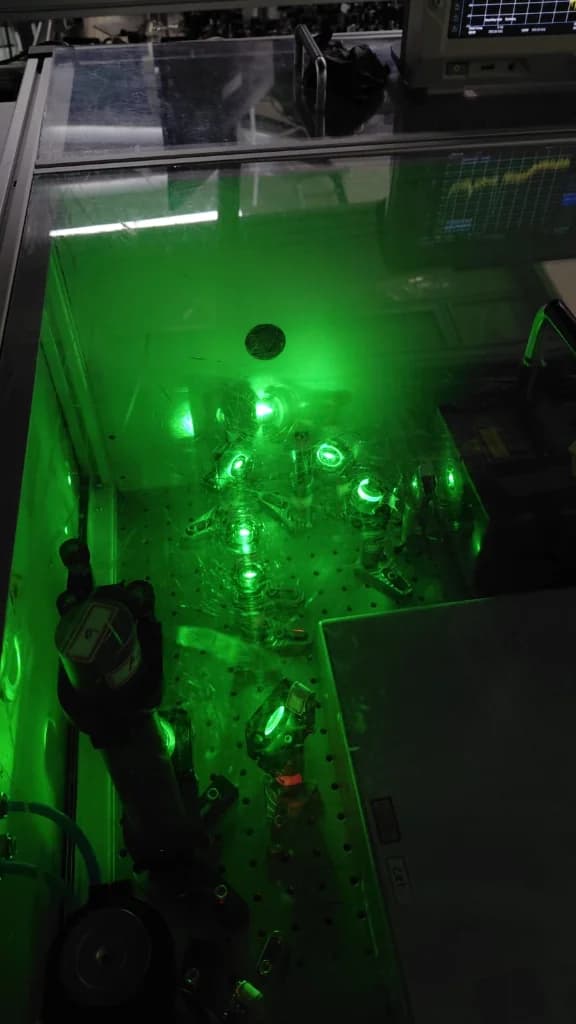
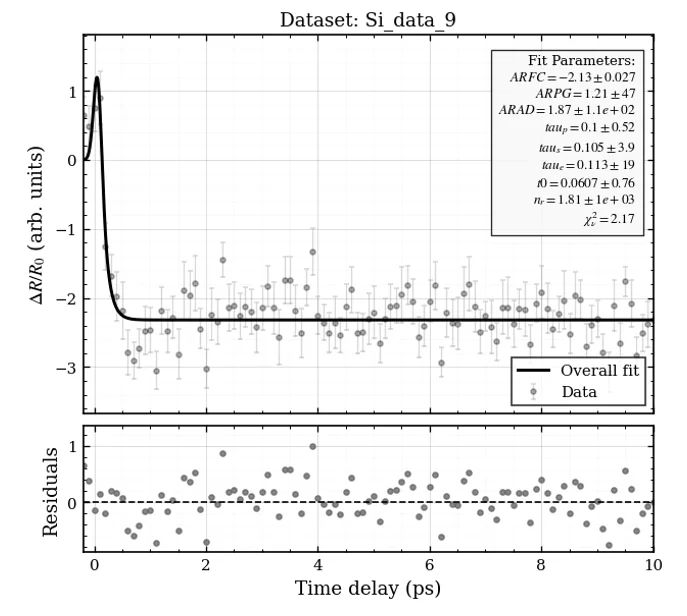
Executed 28-femtosecond pump-probe spectroscopy (800 nm) and THz-TDS measurements, successfully extracting a 32 fs momentum and 260 fs electron-phonon relaxation time.

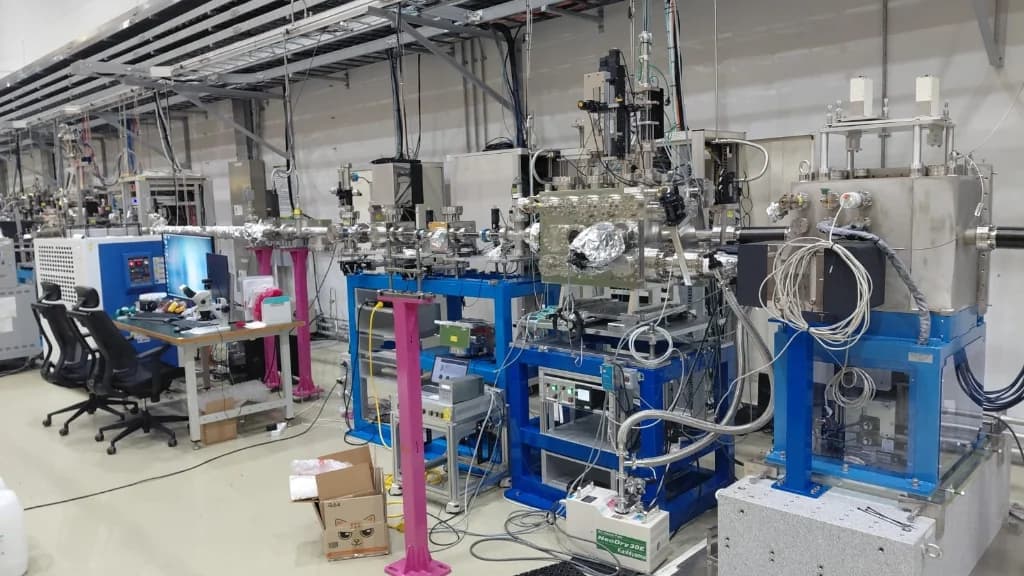
Engineered GPU-accelerated computational imaging pipelines in Python, C++, and CUDA using extended Ptychographic Iterative Engines (ePPM) to reconstruct high-fidelity diffraction images from massive synchrotron datasets.

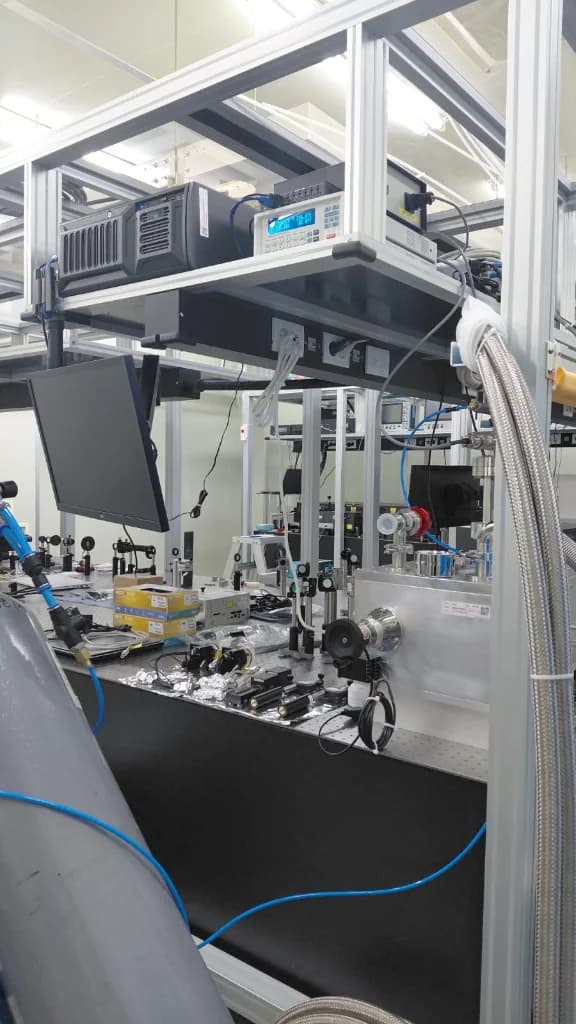
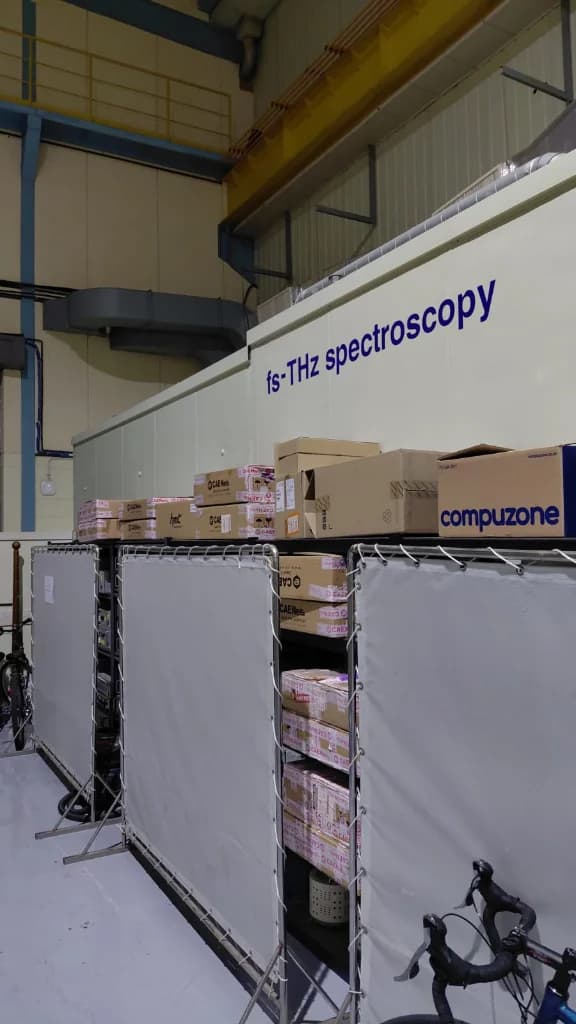
PAL Synchrotron Coherent X-ray Endstation
POHANG ACCELERATOR LABORATORY (PAL) · ENDSTATION
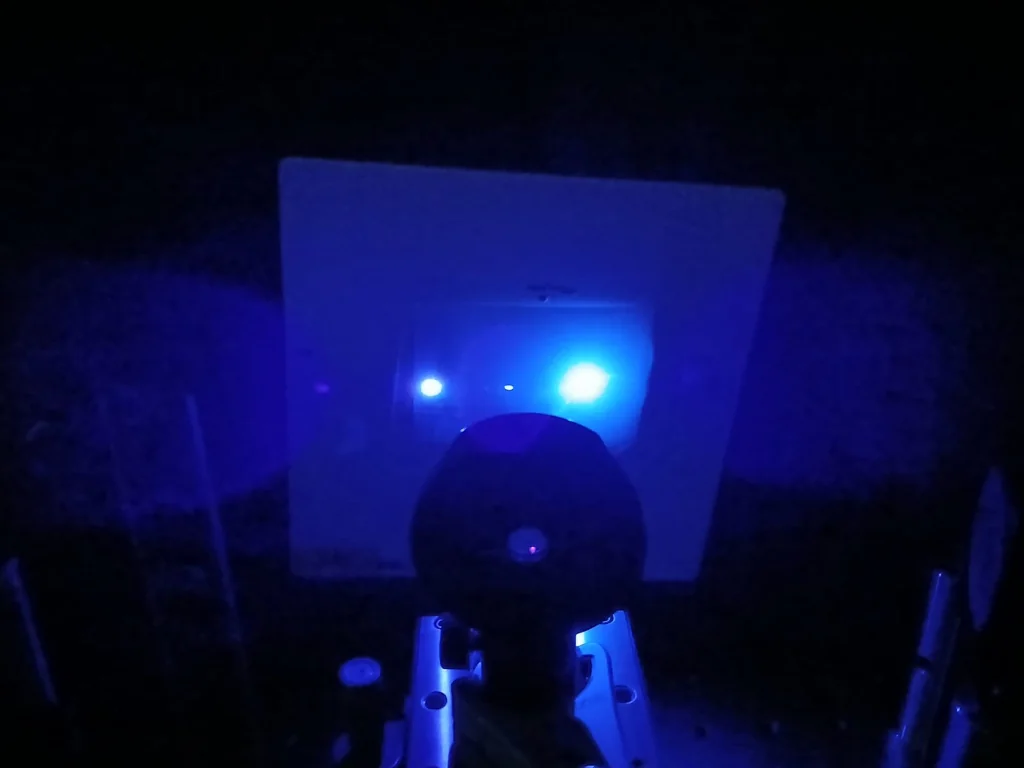
Femtosecond Laser Optical Table
800 nm Ti:SAPPHIRE · 28 fs PULSES
Kamal at POSTECH Lab
Kamal @ POSTECH (APCTP)
Si(001) ΔR/R0 Transient
Si(001) ΔR/R₀ Transient
532 nm Pump Cavity
532 nm Pump Cavity
Coherent Beam Alignment
Coherent THz Beam
Carrier Dynamics Fit
UHV Sample Chamber
UHV Sample Chamber
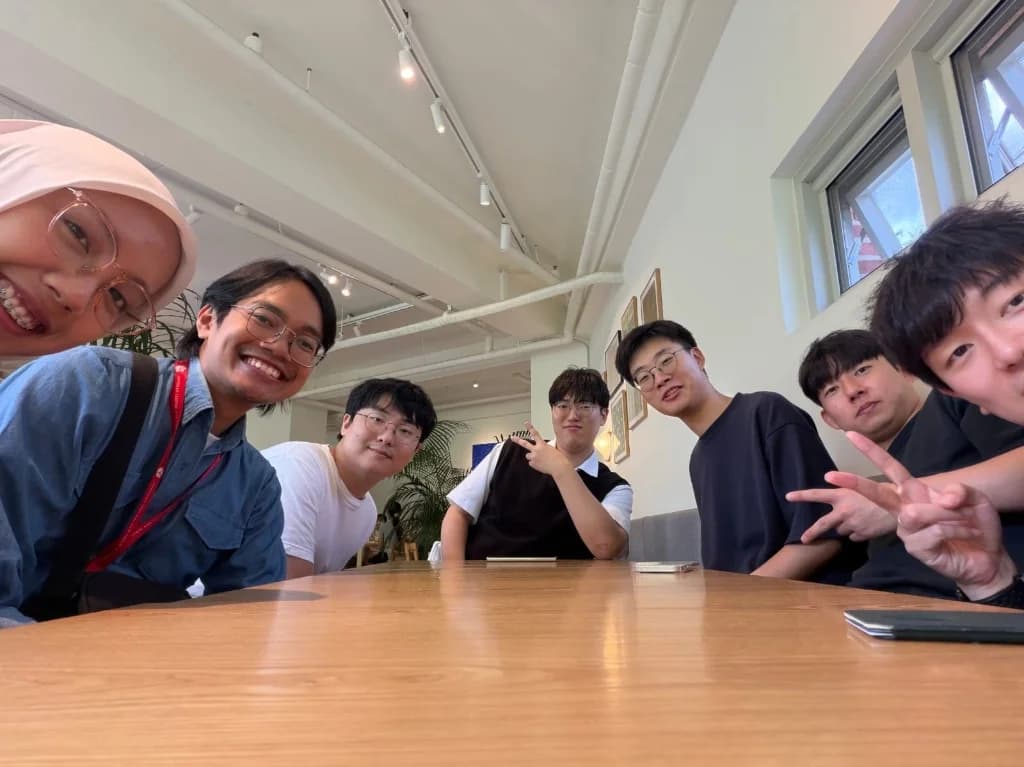
POSTECH Research Group
POSTECH Lab Group
Technologies & Methodologies:
Ultrafast Optics (Femtosecond Laser)Pump-Probe Spectroscopy (28 fs)Terahertz Time-Domain Spectroscopy (THz-TDS)Coherent Diffraction & Ptychography (ePPM)High-Performance Computing (CUDA C++)Python (NumPy, SciPy)Synchrotron Coherent X-Ray ScatteringCarrier Dynamics & RelaxationDigital Signal & Image ProcessingData Acquisition (DAQ)Quantum Condensed Matter Physics
Real Work · Defense R&DDefense Technologies & Spectral Machine Learning
Collaborated withPT Pindad (Persero)

Defense R&D: Raman Spectroscopy ML & Explosives Classifier

This defense-sector R&D initiative at PT. Pindad (Persero) engineered an automated spectral anomaly detection and material classification system to rapidly identify hazardous constituent compounds and energetic defense materials.

I built a predictive machine learning pipeline to classify complex Raman spectroscopy signatures and architected a custom GUI dashboard to acquire and visualize high-resolution spectral data in real time.

The deployed models achieved 80–90% classification accuracy in isolating target hazardous materials while establishing a streamlined, automated workflow that enhanced high-fidelity analysis and personnel safety.

Technologies & Methodologies:
Raman SpectroscopyChemometrics & Spectral ProcessingMachine Learning ClassificationScikit-LearnSciPy & NumPyPythonBaseline Correction & Savitzky-Golay FilteringDimensionality Reduction (PCA, t-SNE)Real-Time Data Acquisition (DAQ GUI)Explosives & Hazardous Materials DetectionModel Validation (Cross-Validation, ROC-AUC)
University · Coursework ProjectIIoT & Systems Architecture · Real-Time Control
Course Project
ITB
TF4107 IIoT
Omron CP2E

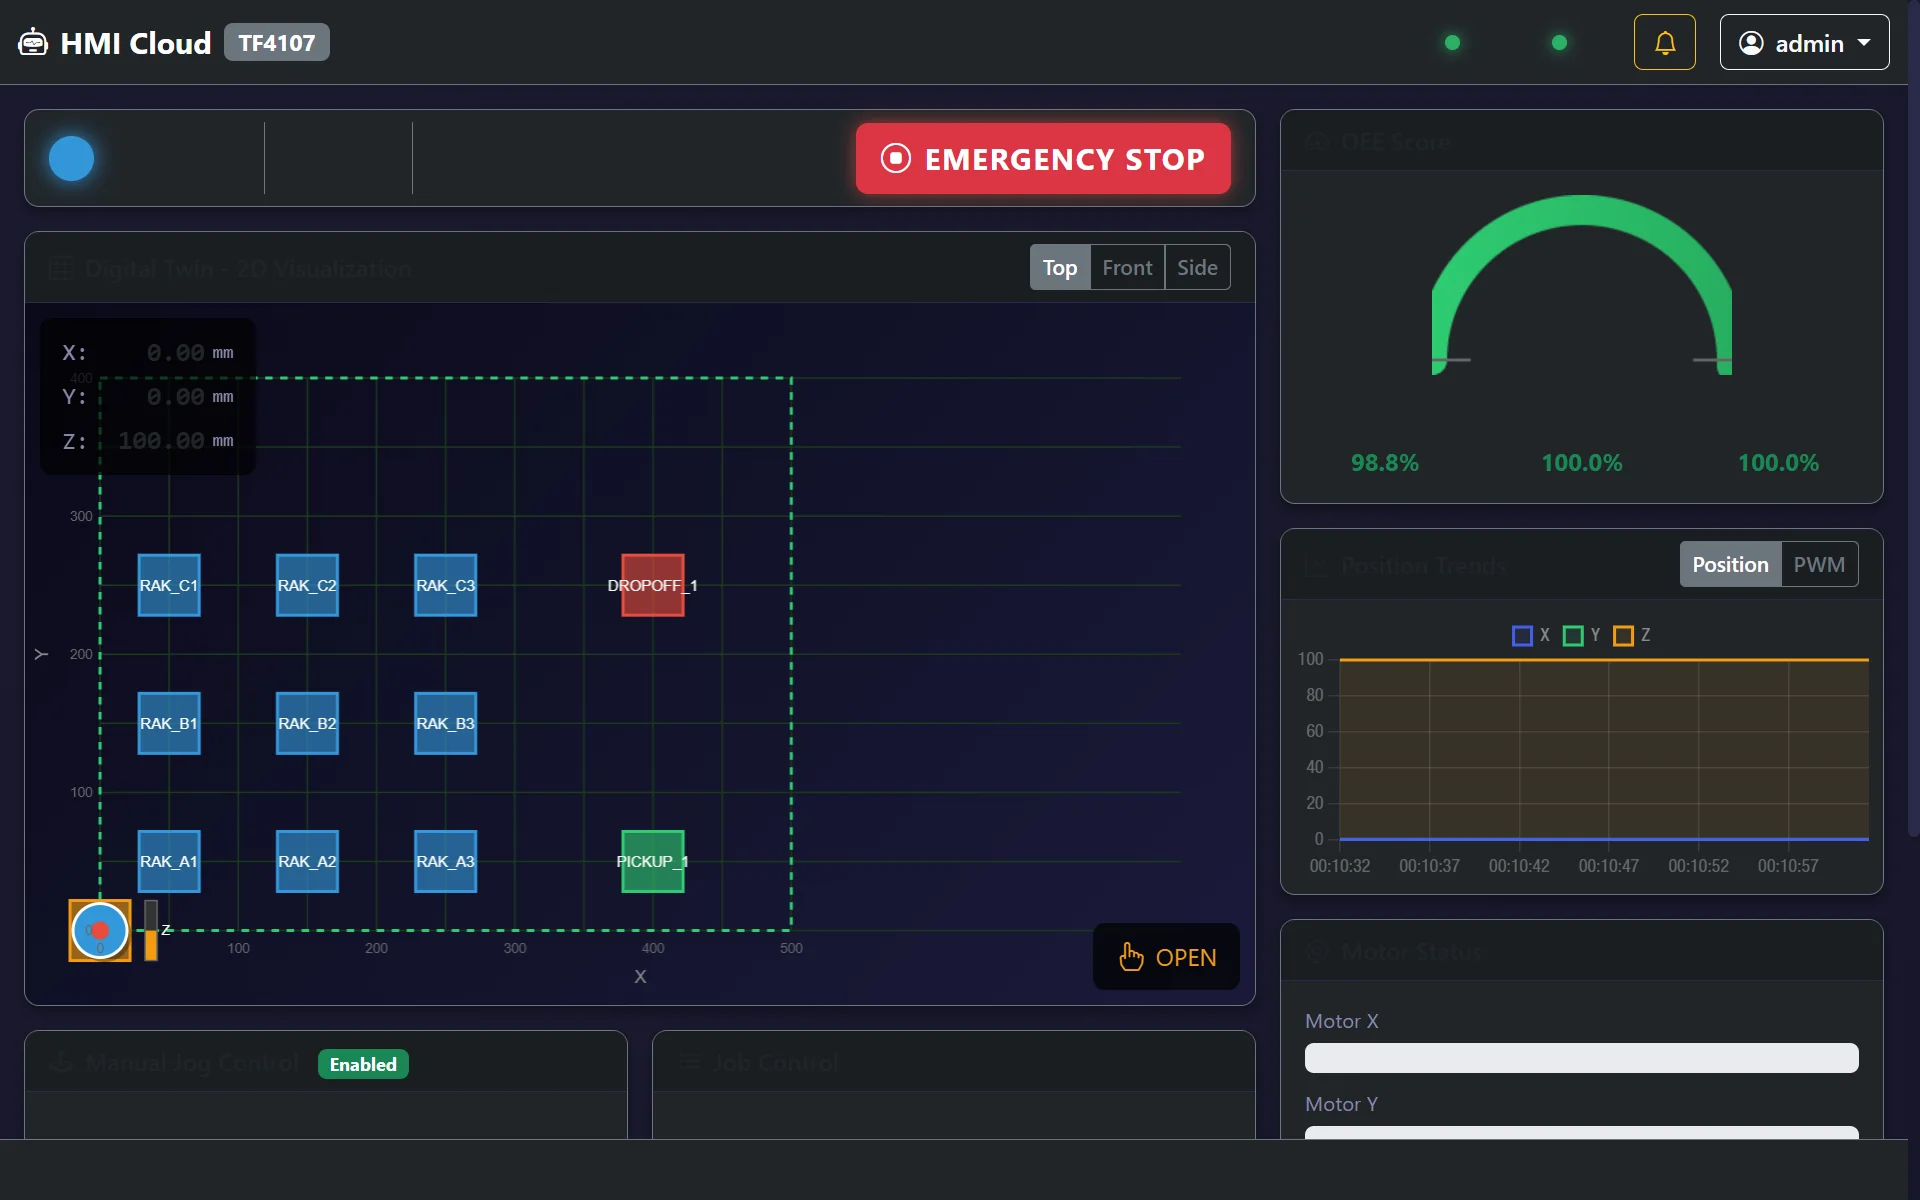
HMI Cloud: Full-Stack IIoT Ecosystem & 2D Digital Twin for Gantry Robot

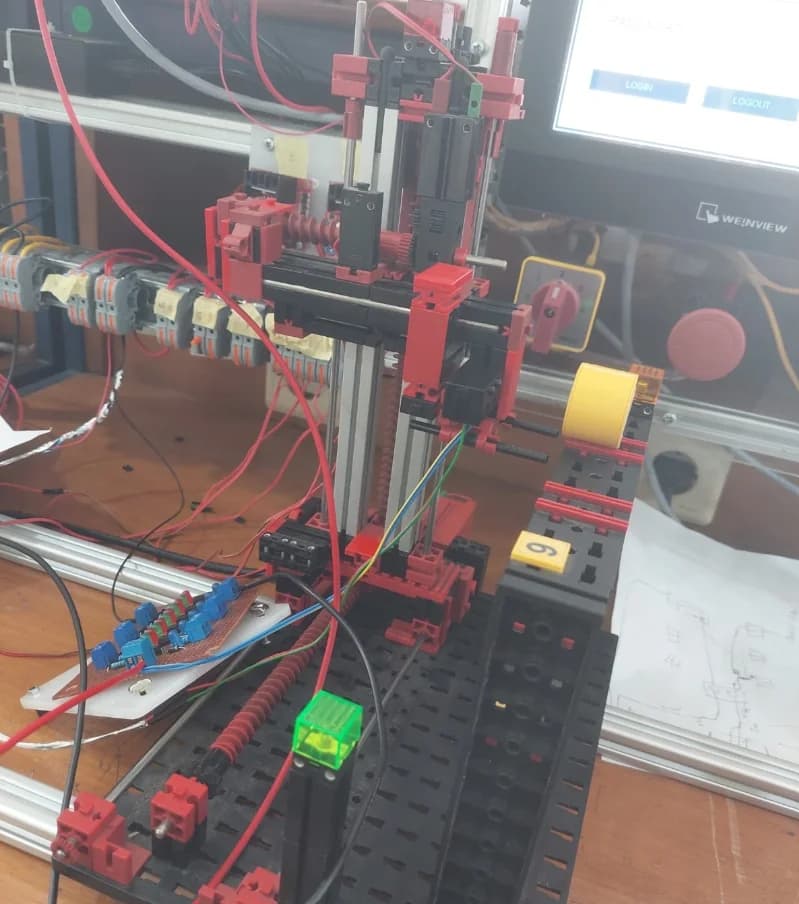
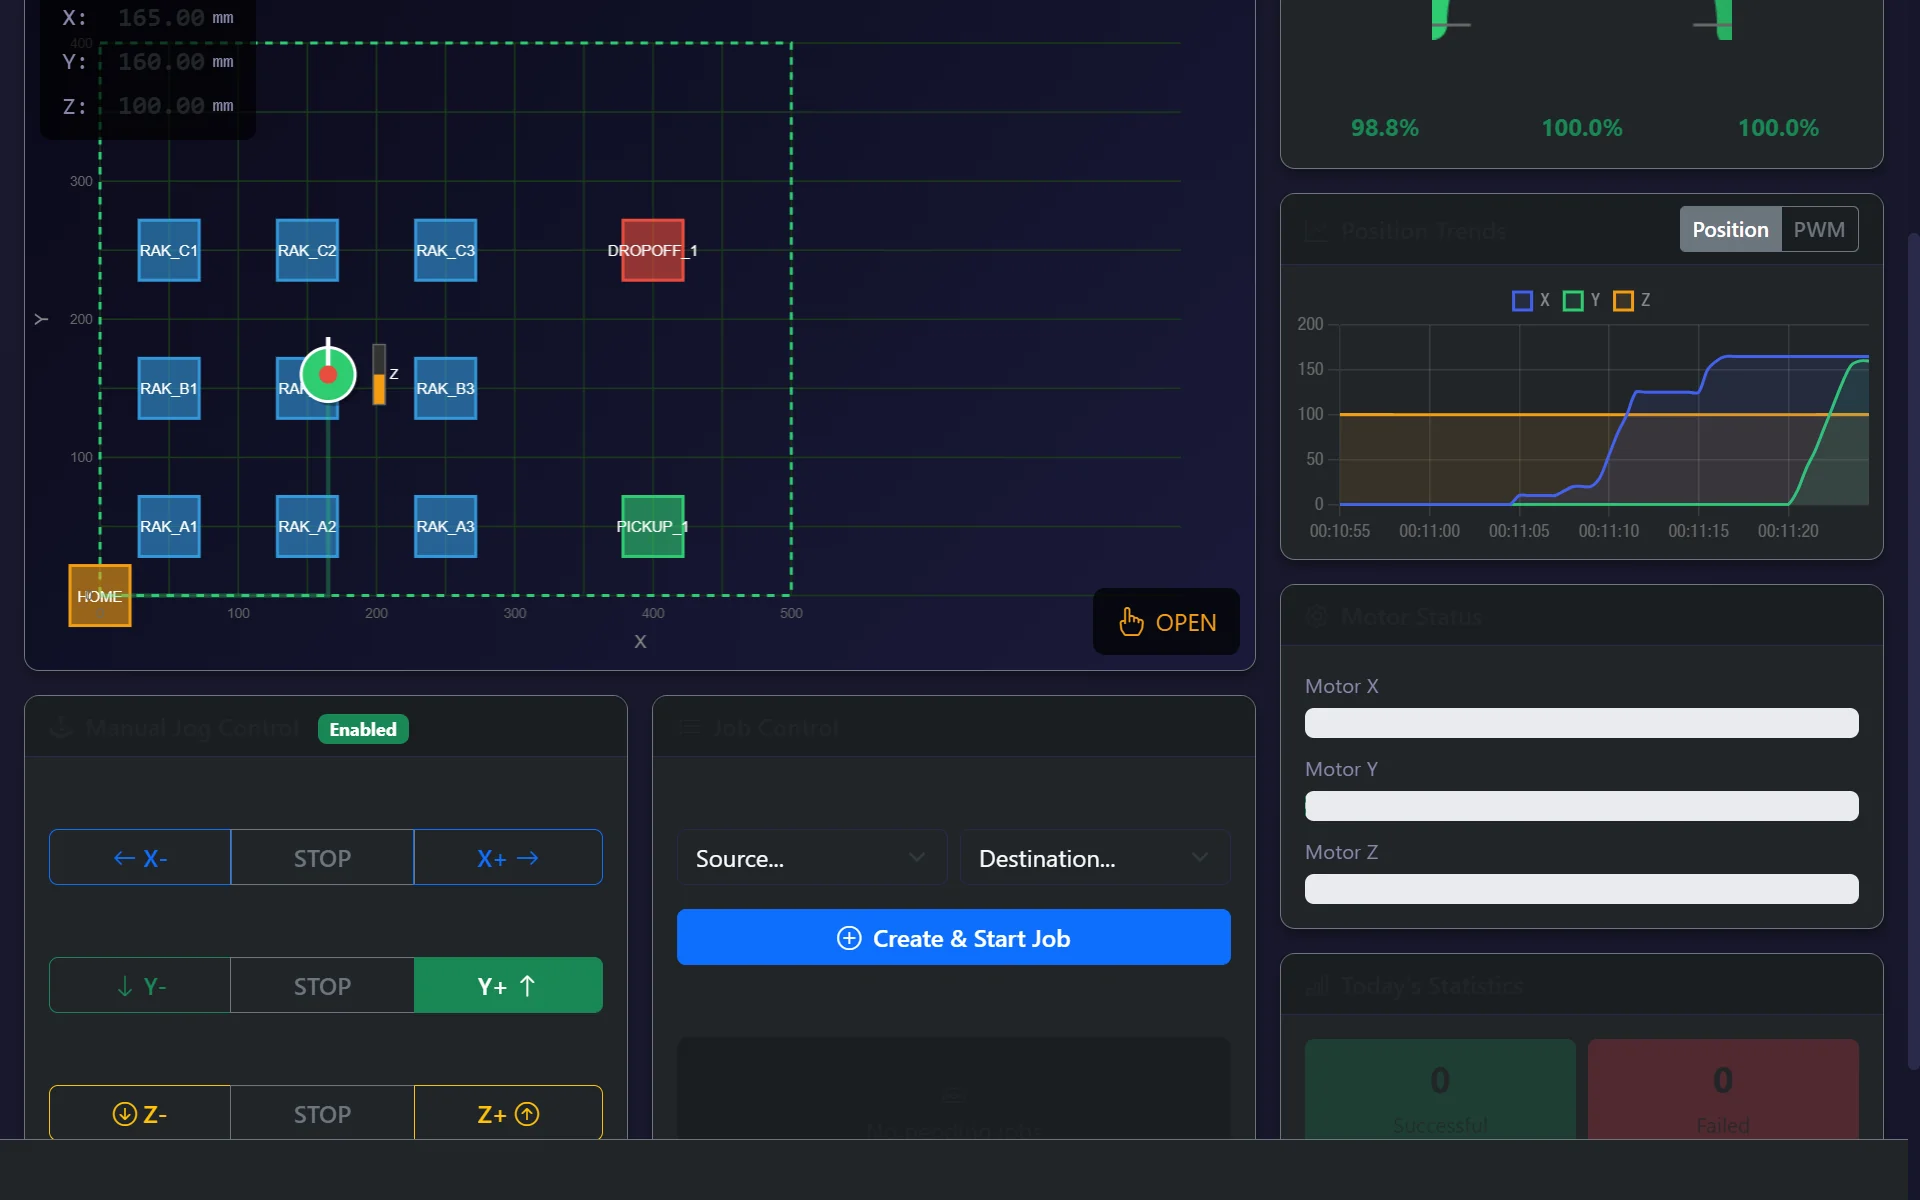
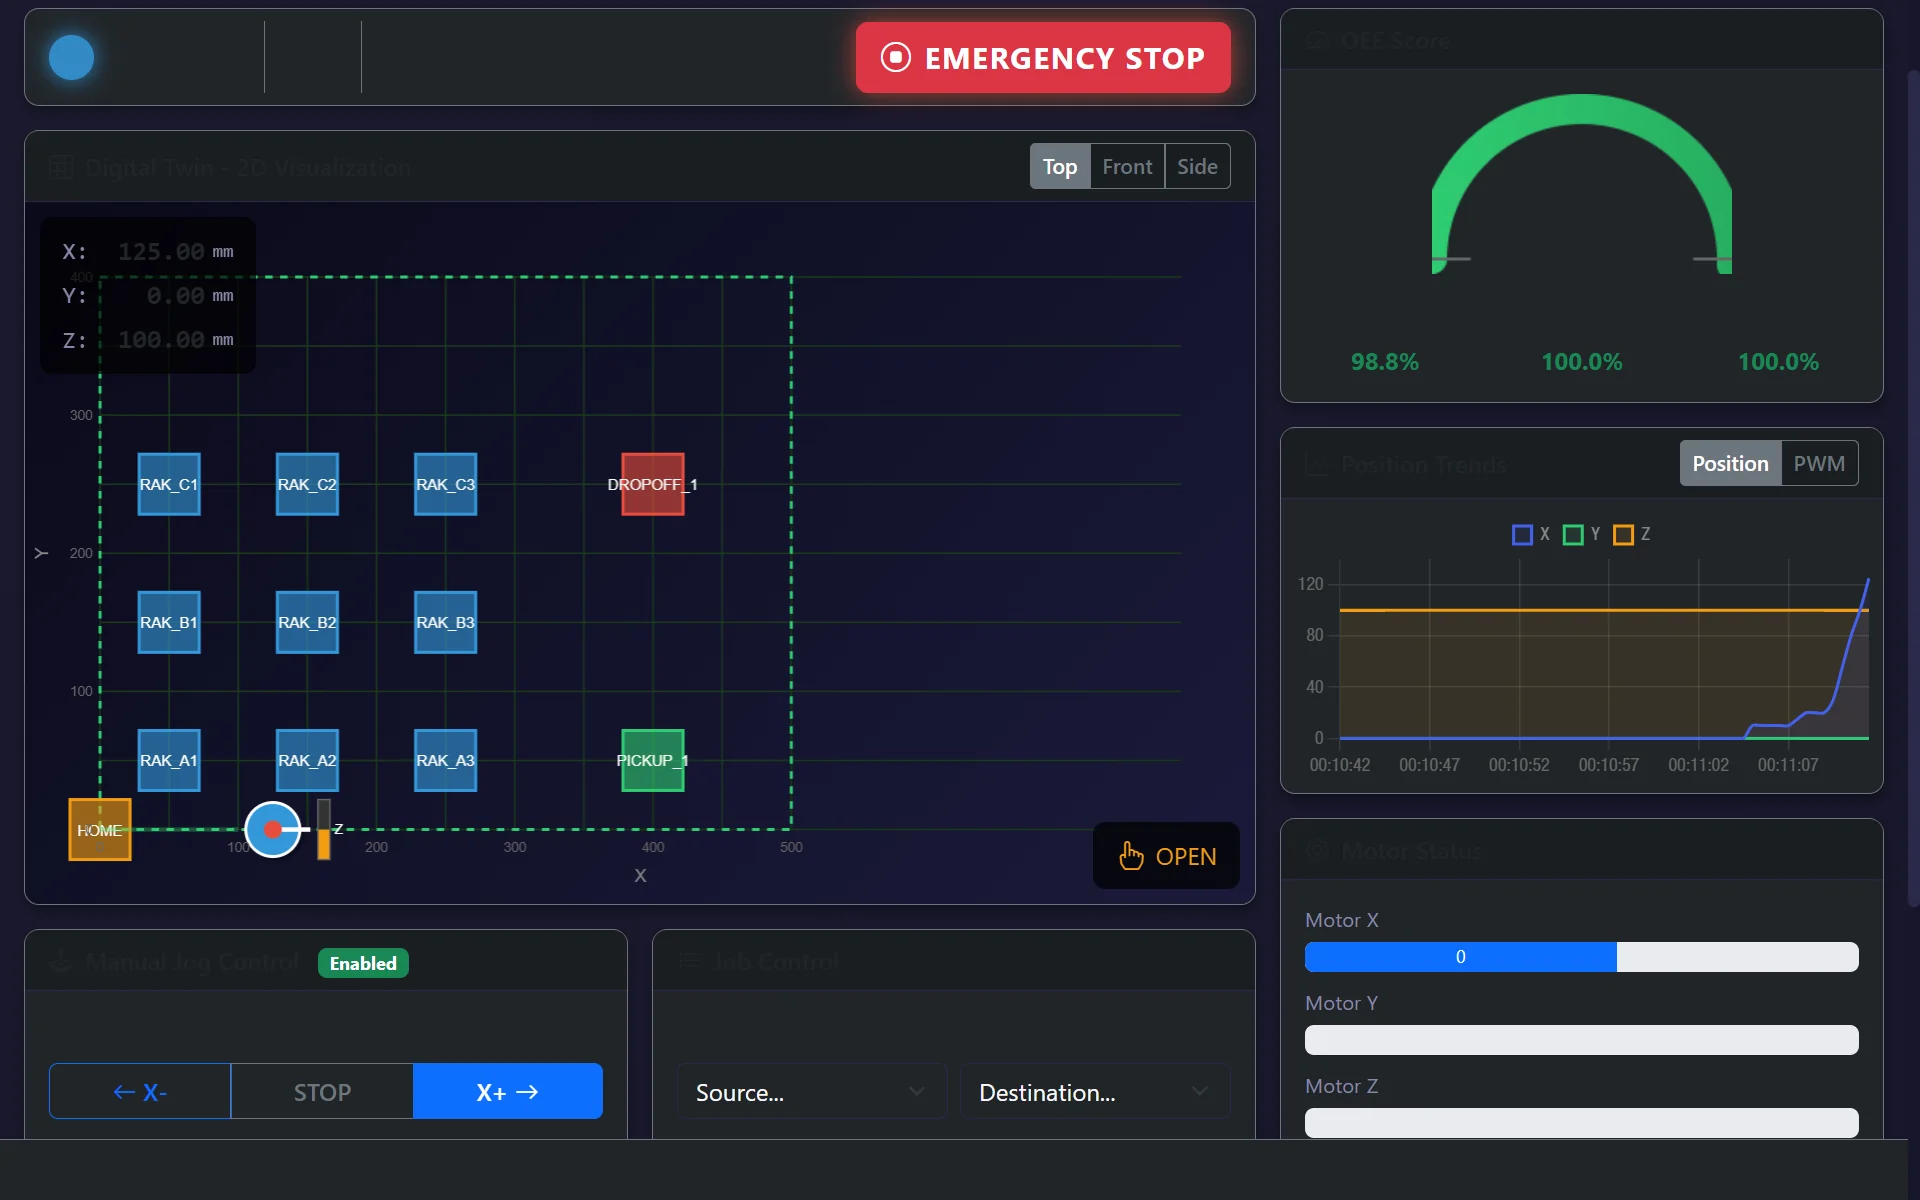
A comprehensive Industrial Internet of Things (IIoT) Human Machine Interface (HMI) engineered for the Fischertechnik 3-axis Gantry Robot, architecting a full-stack cloud ecosystem to enable remote 2D Digital Twin visualization, high-frequency telemetry tracking, and automated industrial analytics.

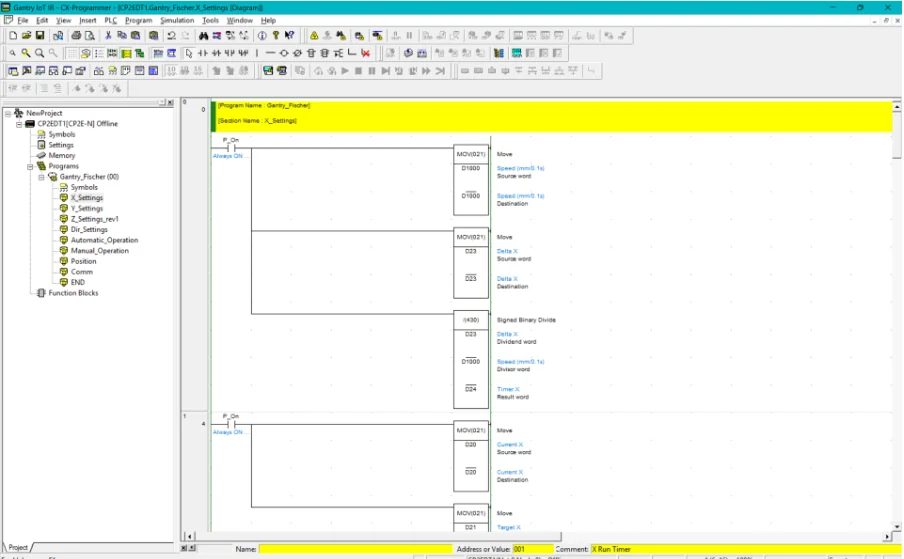
Developed a bi-directional protocol gateway via Node-RED and Omron FINS Protocol, directly bridging Omron CP2E PLC memory addresses (D-registers) with Node.js and Socket.io/MQTT to achieve millisecond-accurate tracking of robot X, Y, and Z coordinates alongside remote automated job dispatching, PWM motor control, and encoder feedback loops.

Engineered an automated OEE calculation engine (Availability, Performance, Quality) within a PostgreSQL time-series schema, benchmarking operational efficiency against a target of >85% to diagnose systemic bottlenecks. Implemented a multi-tier RBAC and JWT authentication framework securing manual jog controls and emergency-stop safety protocols across three distinct clearance levels.

2D Digital Twin HMI Dashboard
2D DIGITAL TWIN · REAL-TIME TELEMETRY
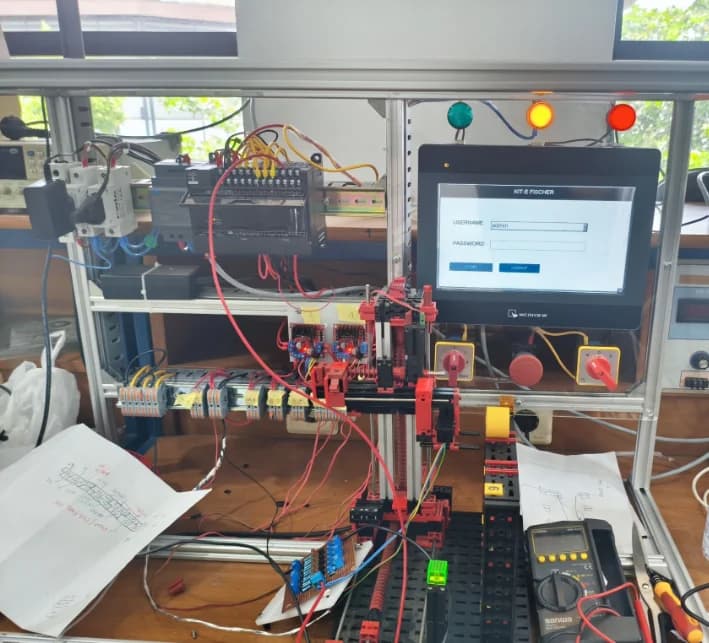
Industrial Hardware Testbed & Omron PLC
WEINVIEW HMI & OMRON CP2E PLC RIG
Omron CP2E Ladder Diagram
Omron CP2E Ladder
Fischertechnik Gantry Carriage
3-Axis Gantry Robot
Technologies & Methodologies:
Industrial IoT (IIoT)PLC Programming (Ladder Logic, Omron CP2E)Industrial Communication (FINS, Modbus TCP/IP)SCADA / HMI ArchitectureDigital Twin SimulationReal-Time WebSockets (Socket.io)TypeScript / Next.jsNode.jsPostgreSQL (Time-Series Data)Overall Equipment Effectiveness (OEE)Closed-Loop Motor Control (PWM, Encoders)
University · Coursework ProjectControl Systems & Deep RL · Autonomous Vehicles
Course Project
ITB
TF4017 Robotics & Automation
MATLAB & Simulink

Active Suspension Systems: Comparative Analysis of LQR vs. Deep Reinforcement Learning

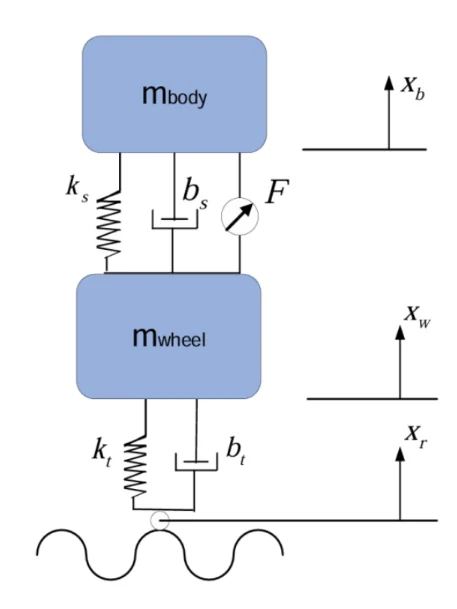
Deconstructed a 2-DOF Quarter-Car Active Suspension Model using Lagrange-Euler dynamics into a 4th-order state-space representation (ẋ = Ax + Bu) to optimize cabin vibration isolation and ride stability for autonomous vehicle platforms against stochastic road profiles, verifying full-state feedback feasibility by mathematically proving a Rank of 4 through MATLAB Controllability and Observability Gramian matrix analysis.

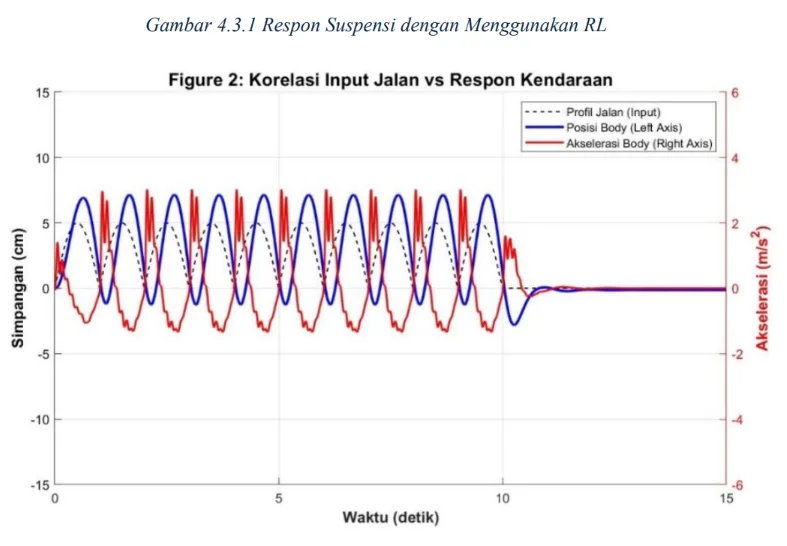
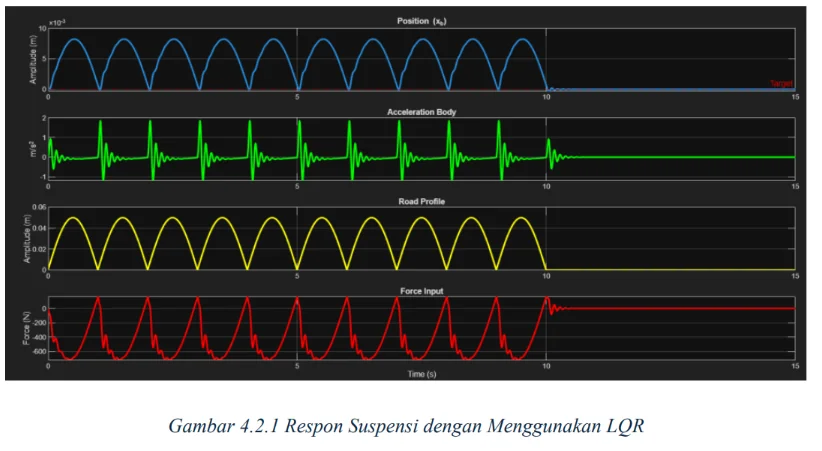
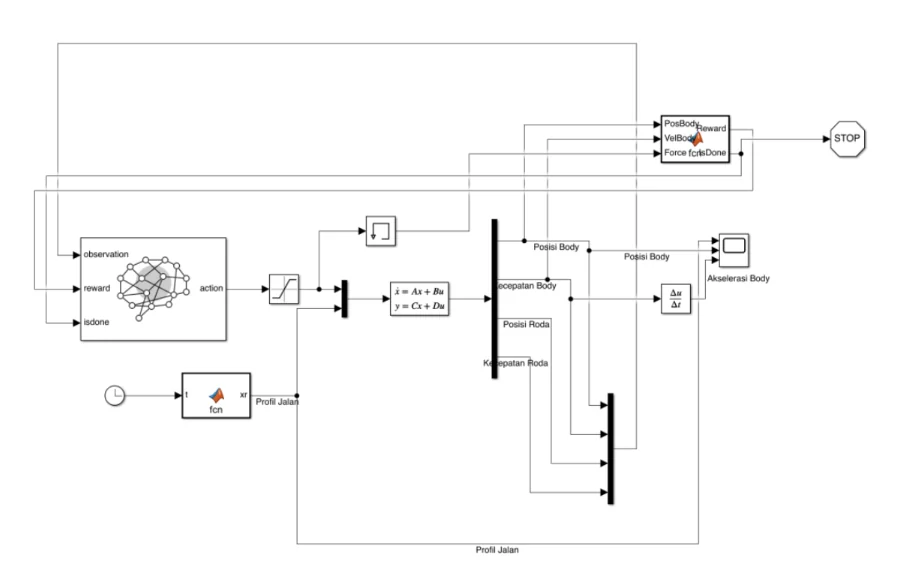
Benchmarked an optimal model-based Linear Quadratic Regulator (LQR) designed via algebraic Riccati solvers against a model-free Deep Deterministic Policy Gradient (DDPG) agent trained over 500+ episodes in MATLAB & Simulink across continuous action bounds (±3000 N). In Hardware-in-the-Loop style simulations across 5 cm sinusoidal road profiles, LQR achieved a >80% disturbance attenuation rate and 0.115-second settling time, demonstrating decisive transient precision over RL (ITAE: 1.71 vs. 58.02).

Deep RL Suspension Response
BENCHMARK RESULT · DDPG AGENT RESPONSE
LQR Suspension Response
LQR CONTROLLER · TRANSIENT RESPONSE
2-DOF Quarter-Car Model
2-DOF Quarter Car
Simulink RL Architecture
Technologies & Methodologies:
Optimal Control Theory (LQR / LQG)Deep Reinforcement Learning (DDPG, Actor-Critic)State-Space Modeling (4th-Order ẋ = Ax + Bu)Controllability & Observability AnalysisMATLAB & SimulinkPython (Gymnasium, PyTorch)Dynamic System Simulation (2-DOF Quarter-Car)Non-linear Vibration AttenuationActive Suspension SystemsFrequency-Domain & Transient Response
Academic Track Record

Publications & Preprints

Peer-reviewed conference proceedings and scientific journal articles across robotics, computer vision, sensor instrumentation, and applied machine learning.

5 Published Works
2025Conference Proceeding
doi:10.1063/12.0044742

Implementation of a Lightweight Deep Stereo Matching Network in Mobile Robot for Volcano Monitoring Application

Authors: Muhammad Kamal, Maria Evita, Arief Suryadi Satyawan, Mitra Djamal

Venue: AIP Conference Proceedings, Volume 3504, Issue 1, 020010 (ISNPINSA)

Core Finding

Evaluated and deployed lightweight deep stereo disparity networks on a custom passive stereo rig for the PRAWIRA mobile robot, overcoming textureless volcanic ash and specular rock depth failures within strict embedded power budgets.

2025Conference Proceeding
doi:10.1063/12.0044731

Implementation of a Lightweight Monocular Metric Depth Estimation Network in Mobile Robot for Volcano Monitoring Application

Authors: Muhammad Kamal, Maria Evita, Arief Suryadi Satyawan, Mitra Djamal

Venue: AIP Conference Proceedings, Volume 3504, Issue 1, 020009 (ISNPINSA)

Core Finding

Benchmarked lightweight zero-baseline monocular metric depth networks including ZoeDepth, Depth Pro, and Lite-Mono against RealSense D435i and Astra Pro ground truth, enabling 3D metric spatial awareness on embedded single-board computers for volcanic search-and-rescue.

2025Conference Proceeding
doi:10.1063/12.0044740

A Machine Learning Framework for Checking the Consistency of Core Fluorescence Image Data with Well-Log Resistivity Measurements in Petrophysics

Authors: Muhammad Kamal, Pahala Dominicus Sinurat

Venue: AIP Conference Proceedings, Volume 3504, Issue 1 (ISNPINSA)

Core Finding

Extracted quantitative color metrics from 706 depth-matched ultraviolet core images to train an XGBoost multimodal regression pipeline, validating petrophysical property consistency with subsurface resistivity logs at an R2 of 0.882 for automated hydrocarbon screening.

Analysis of Temperature Sensors in a Volcanic Detection System

Authors: Abdul Muid, I Kadek Sawita, Nazira Appriyana, Alfi Nur Albab, Darell Tarigan, Muhammad Kamal, Maria Evita, Suprijadi Suprijadi, Mitra Djamal

Venue: Indonesian Journal of Physics, Volume 36, Issue 1, Pages 1-10

Core Finding

Characterized multi-point ambient temperature telemetry arrays and integrated a 256-rule fuzzy logic inference engine to classify active volcanic hazards into real-time operational alert tiers.

Alat Deteksi Denyut Jantung Tipe Fingertip dengan Sensor Non-invasif untuk Masyarakat Pedesaan (Studi Kasus Desa Raharja, Banjar, Jawa Barat)

Authors: Maria Evita, Jihan Prihatini, I Kadek Agus Sara Sawita, Muhammad Kamal, Nur Asiah Aprianti

Venue: Jurnal Fisika Unand, Volume 14, Issue 5, Pages 500-506

Core Finding

Engineered an affordable non-invasive photoplethysmography device combining infrared sensing, active analog filtering, and Arduino processing that met clinical diagnostic accuracy benchmarks during community health screenings in rural Raharja Village.

Primary Track Record

Professional & Research Experience

Creating real-world impact across scientific research and engineering practice.

In research: pushing frontiers in applied physics, autonomous navigation, and novel physical sensing.

In work: architecting resilient edge systems, high-precision robotics, and sub-millisecond automation for field deployments.

Jun 2026 – Aug 2026

Undergraduate Student Researcher (Ultrafast Quantum Physics)

atPOSTECH (Pohang University of Science & Technology)

Investigated sub-picosecond carrier dynamics and spin-phonon coupling in bulk tungsten, Si(001), and altermagnets (MnF₂) under Prof. Changyong Song and Jungchan Choi, executing 28-femtosecond pump-probe spectroscopy (800 nm) and THz-TDS measurements.

Core Deliverable → Extracted 32 fs momentum and 260 fs electron-phonon relaxation times; engineered GPU-accelerated computational ptychography pipelines in C++, CUDA, and Python using extended Ptychographic Iterative Engines (ePPM) to reconstruct high-fidelity phase images from synchrotron datasets.
Apr 2026 – Aug 2026

Embedded Machine Learning Engineer (Computer Vision & Anomaly Detection)

atPT LAPI ITB

Ported a TensorRT-optimized computer vision pipeline (YOLOv8, SAM2, RT-DETR) onto Jetson Orin Nano edge servers, clearing memory bottlenecks to hold 24/7 gas plume segmentation at 30 FPS across 3+ industrial monitoring sites without thermal throttling, fusing legacy point telemetry with PTZ-mounted MWIR optical gas imaging cameras.

Core Deliverable → Cut leak identification latency to under 120 ms, reduced false-positive alerts by 45% through specialized thermal models (GasSeg, LangGas, CGNet), and benchmarked hardware configurations over 20+ runs to eliminate integration errors.
Oct 2025 – Aug 2026

Junior Petrophysicist & Subsurface AI Researcher

atPT LAPI ITB

Modeled probabilistic GIIP volume assessments for Anambas offshore exploration wells together with KUFPEC and Halliburton, running QA/QC and multi-parameter sensitivity analyses to de-risk multi-million-dollar investments across 10+ client deliverables for BP, Pertamina, Halliburton, and KUFPEC.

Core Deliverable → Automated Python and Julia ML pipelines with tensor models to impute missing well logs and analyze core scanner data (LIBS, XRF, hyperspectral, RGB core photo), accelerating interpretation timelines by 45% and hardcoding Modified Simandoux and Thomas-Stieber models for LRLC reservoirs.
Beyond Research & Engineering

Mentoring, Organizations & Other Initiatives

Leadership, academic laboratory instruction, curriculum design, and university-level recognition.

Feb 2026 – Jul 2026

Deputy Coordinator & Teaching Assistant

atThermodynamics & Electromagnetism Laboratory ITB

Ran daily laboratory operations for the core physics curriculum, enforced safety standards across 10+ sessions per week, and calibrated sensitive electromagnetic and thermal measurement instrumentation.

Core Deliverable → Guided undergraduate cohorts through complex experimental setups, high-precision data acquisition, and advanced statistical error analysis without equipment clashes.
Jan 2026 – Jul 2026

Head Laboratory Coordinator

atPhysics Electronics & Instrumentation Laboratory ITB

Orchestrated hardware deployment, calibration, and troubleshooting protocols for microcontrollers, advanced sensors, and IoT modules across 9 concurrent practicum sections for a 200+ student cohort (100+ hardware units per semester).

Core Deliverable → Sustained 100% operational uptime, directed teaching assistants in diagnosing embedded system failures before student sessions, and coached staff through advanced training programs on control systems and KiCAD PCB design.
Apr 2025 – Apr 2026

Head of Creative & Branding

atHIMAFI ITB

Issued and rolled out comprehensive visual identity guidelines standardizing all organizational assets, editorial releases, and public communications across university platforms.

Core Deliverable → Unified 50+ publication assets under one visual standard and planned creative content strategy lifting audience engagement across organizational channels.
Quick Takes & Quirks

This & That.

Lifelong learner with too many hobbies and a love to . Full-time , part-time , used to , podcast & , and die-hard fan.
Based in with a $5 soldering iron, microcontrollers, and endless curiosity.
Lightning Round

These are my personal preferences. Do you agree or disagree?

🐱Cat over dogs
✈️window seat over isle seat
☀️hot weather over cold
🍵tea over coffee
🦉night owl over early bird
🧂salty over sweet
💬texting over calling
🦸marvel over DC
🎬Subs over dubs
🚶walk break over coffee break
🤟the rest is negotiable
FAQ

Frequently Asked Questions.
Key details on my background, research interests, engineering workflow, and collaboration.
You've seen what I do.
Need it done? Send the email.

You can email me. I'm always shipping code on GitHub, active on LinkedIn, and occasionally sharing daily life, content, or writings on Instagram.

© 2023–2026 MUHAMMAD KAMAL.BANDUNG, WEST JAVA • INDONESIA